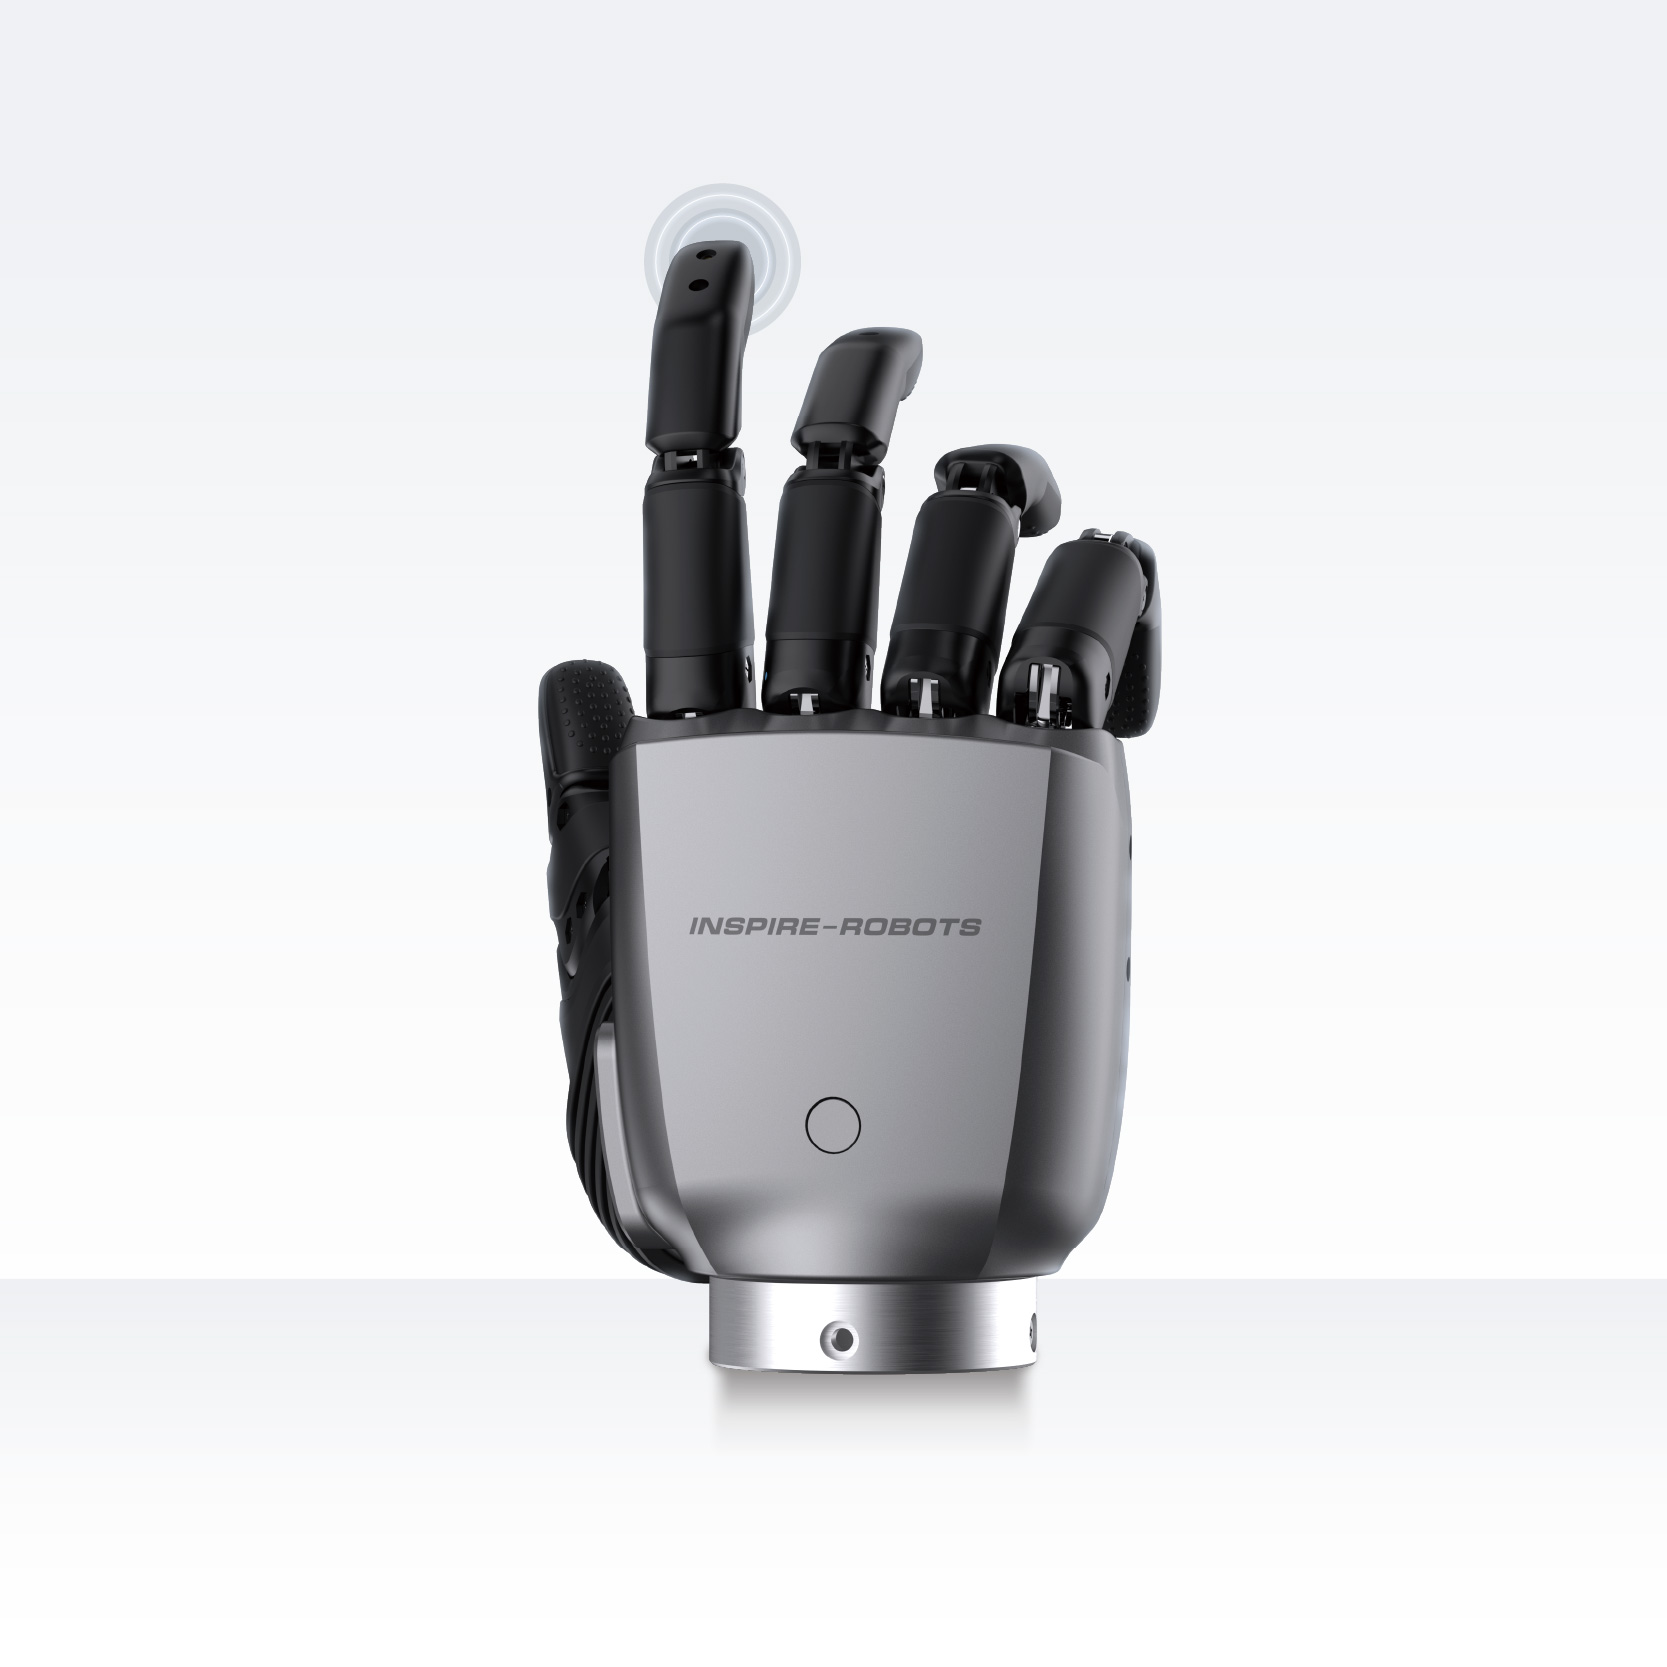
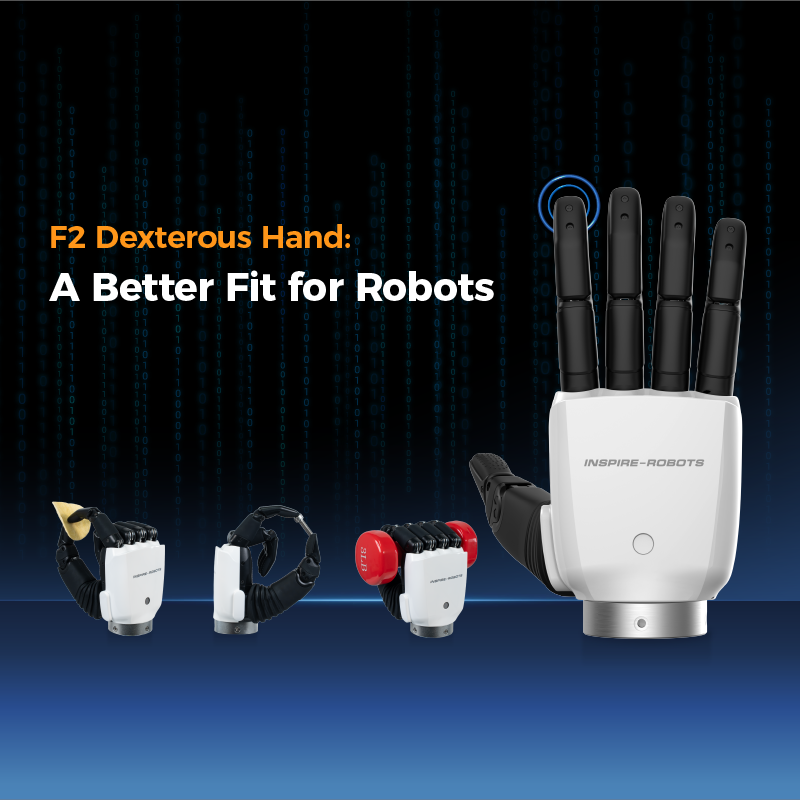
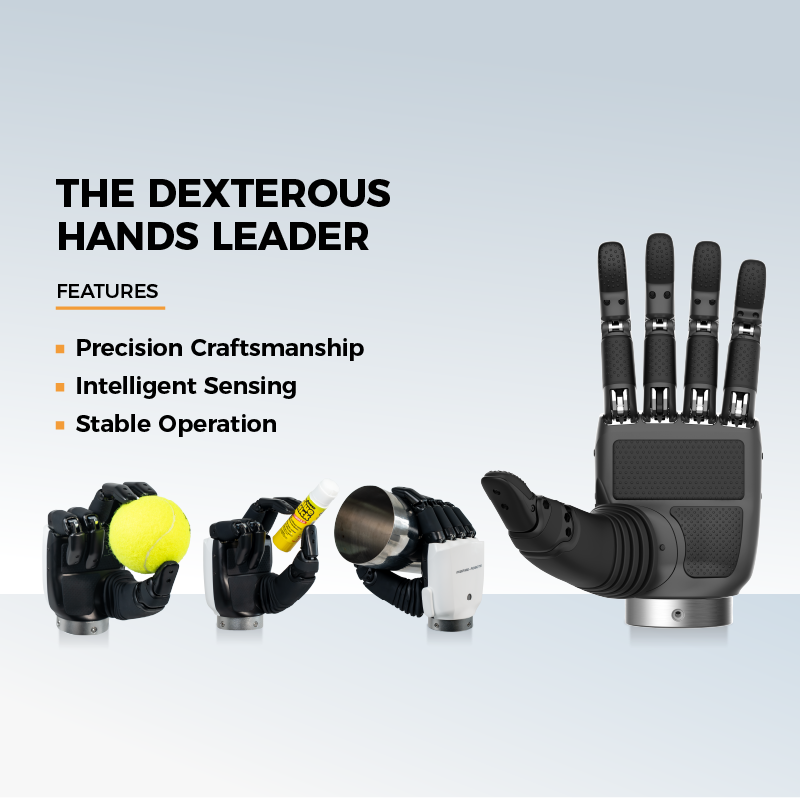
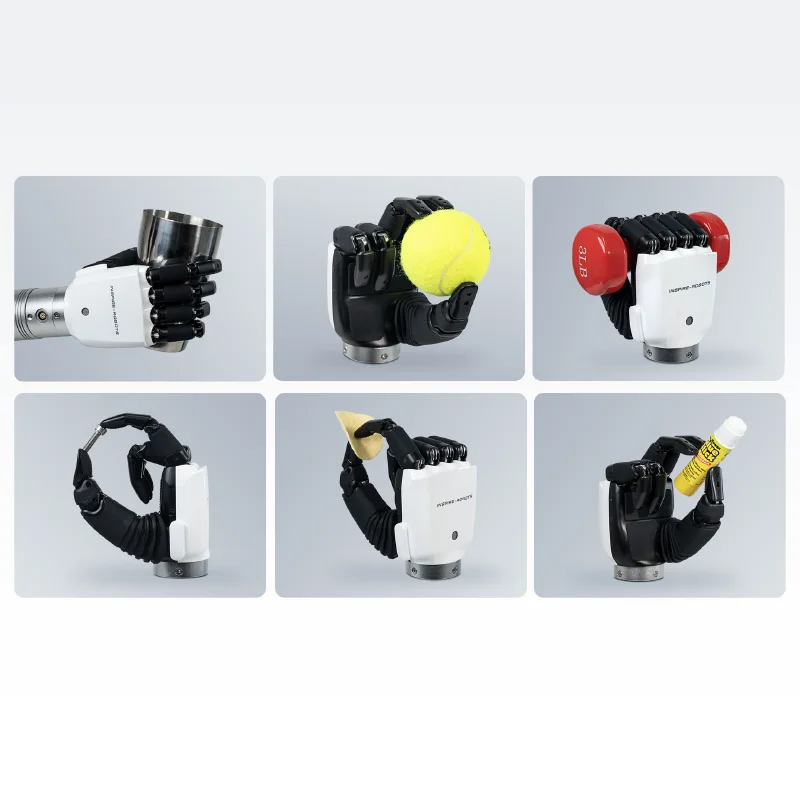
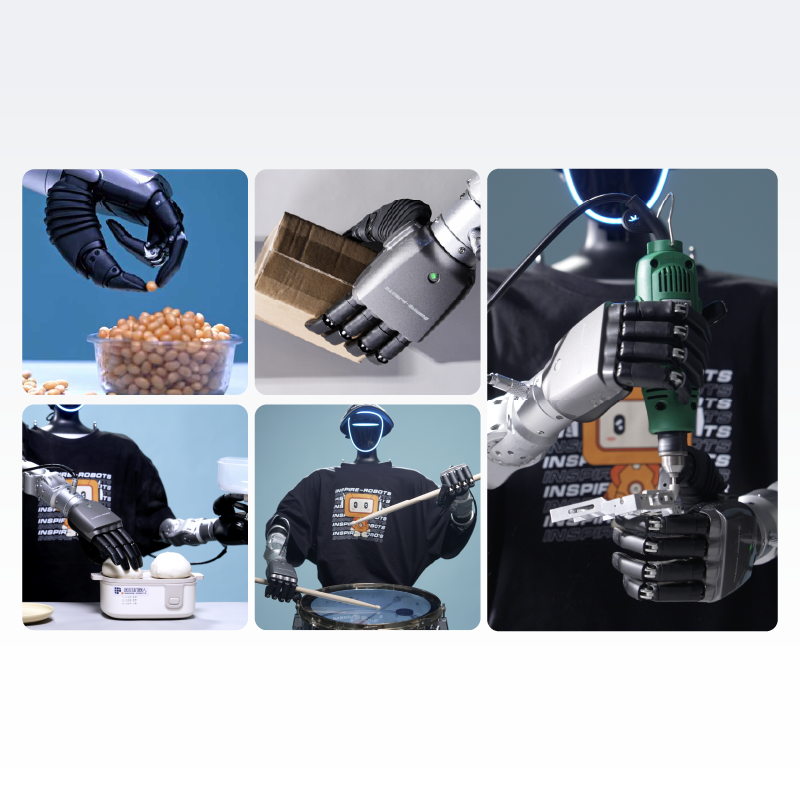
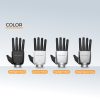
Refined structure, sensitive perception and stable manipulation
| Parameter | RH56F2-E2R-T1 (Right hand model) RH56F2-E2L-T1 (Left hand model) | RH56F2-E4R (Right hand model) RH56F2-E4L (Left hand model) |
| Control interface | EtherCAT+RS485 | EtherCAT+CAN FD |
| Degrees of freedom | 6 | 6 |
| Numbers of joints | 12 | 12 |
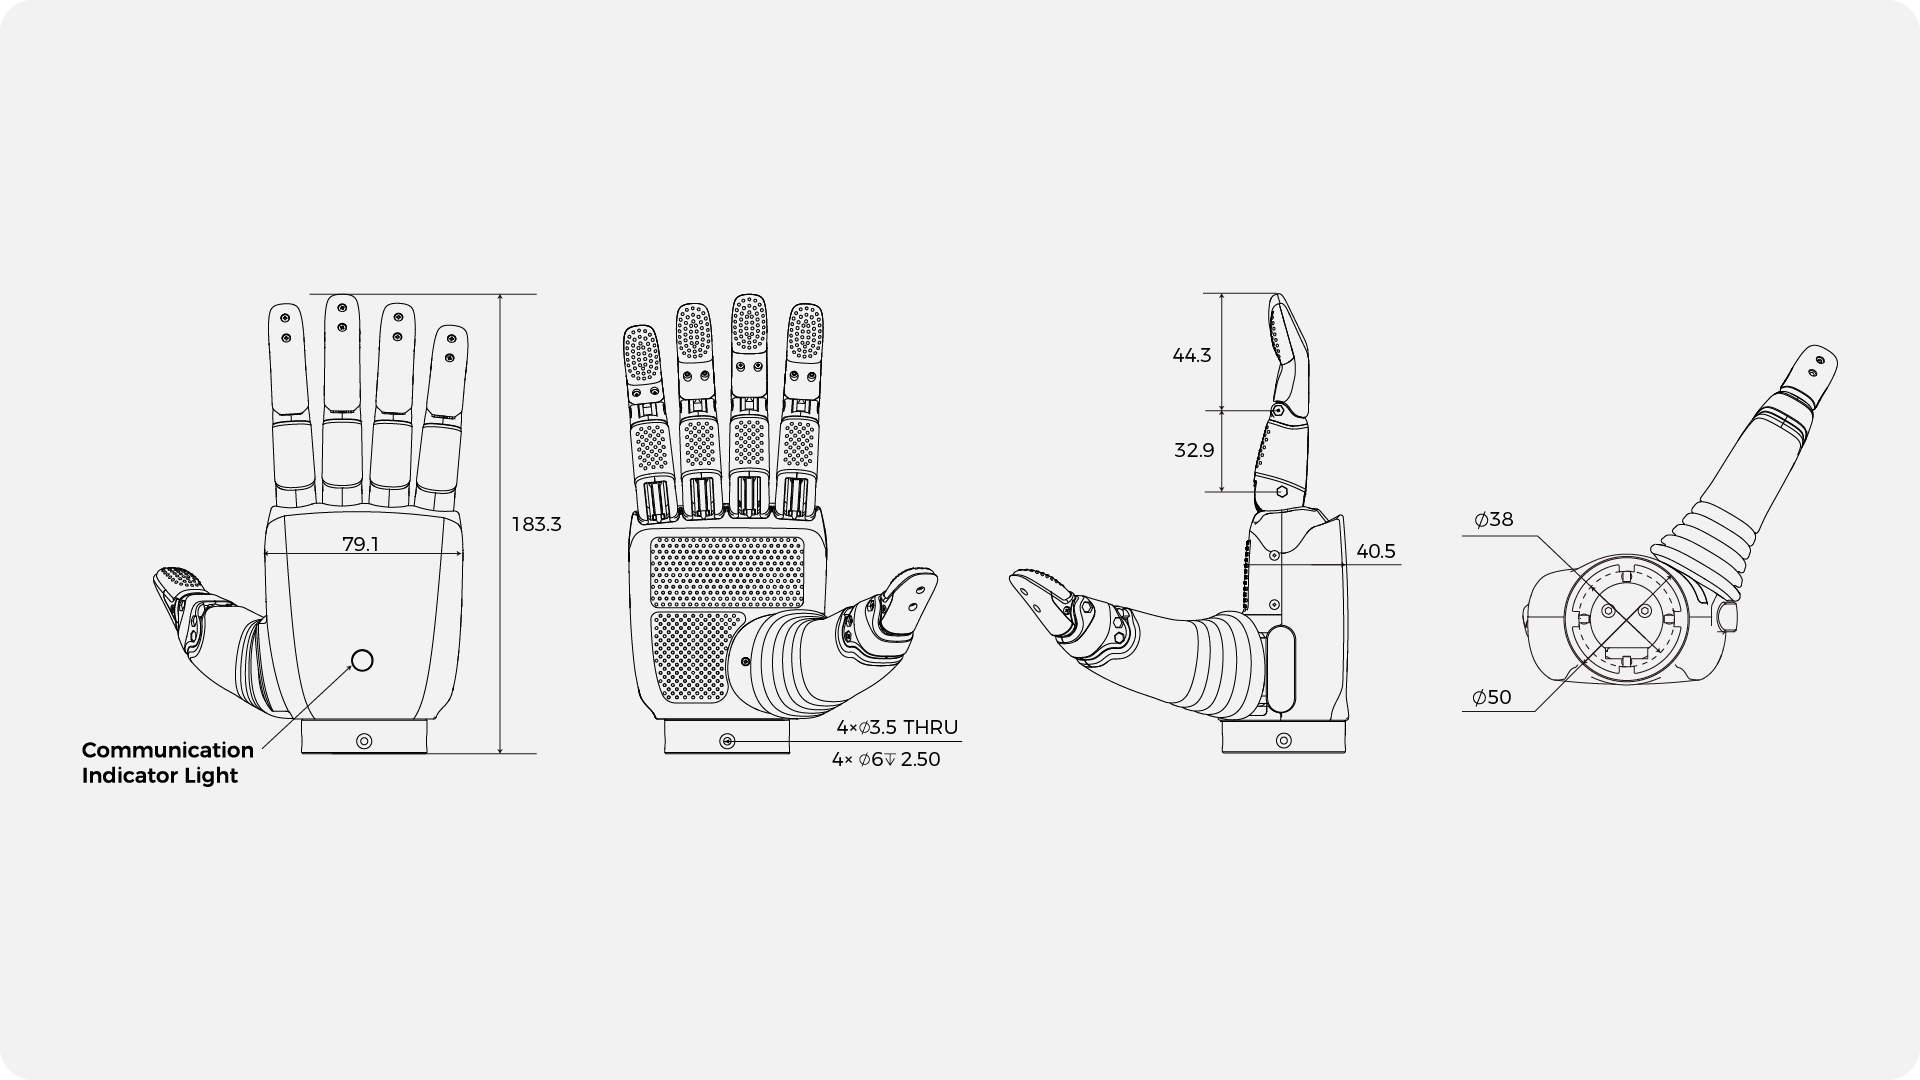
| Weight | 605±10g | 605±10g |
| Operating voltage | 18V~60V | 18V~60V |
| Quiescent current | 150+10mA@24V RS485 160±10mA@24V EtherCAT | 150+10mA@24V CAN FD 160±10mA@24V EtherCAT |
| Peak current | 5A @24V | 5A @24V |
| Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Strength | ≥12N | ≥12N |
| Fingertip Strength | ≥10N | ≥10N |
| Force resolution | 0.1N | 0.1N |
| Lateral rotation range of thumb | 60-180° | 60-180° |
| Lateral rotation speed of thumb | >155°/s | >155°/s |
| Flexion speed of thumb | >37°/s | >37°/s |
| Flexion speed of four finger | >107°/s | >107°/s |
| Range of tactile sensor | 30N | 30N |
| Tactile sensor accuracy | 5%FS | 5%FS |
| Number of tactile sensors | 8 | 8 |
| Hand closing time | ≤0.8s | ≤0.8s |