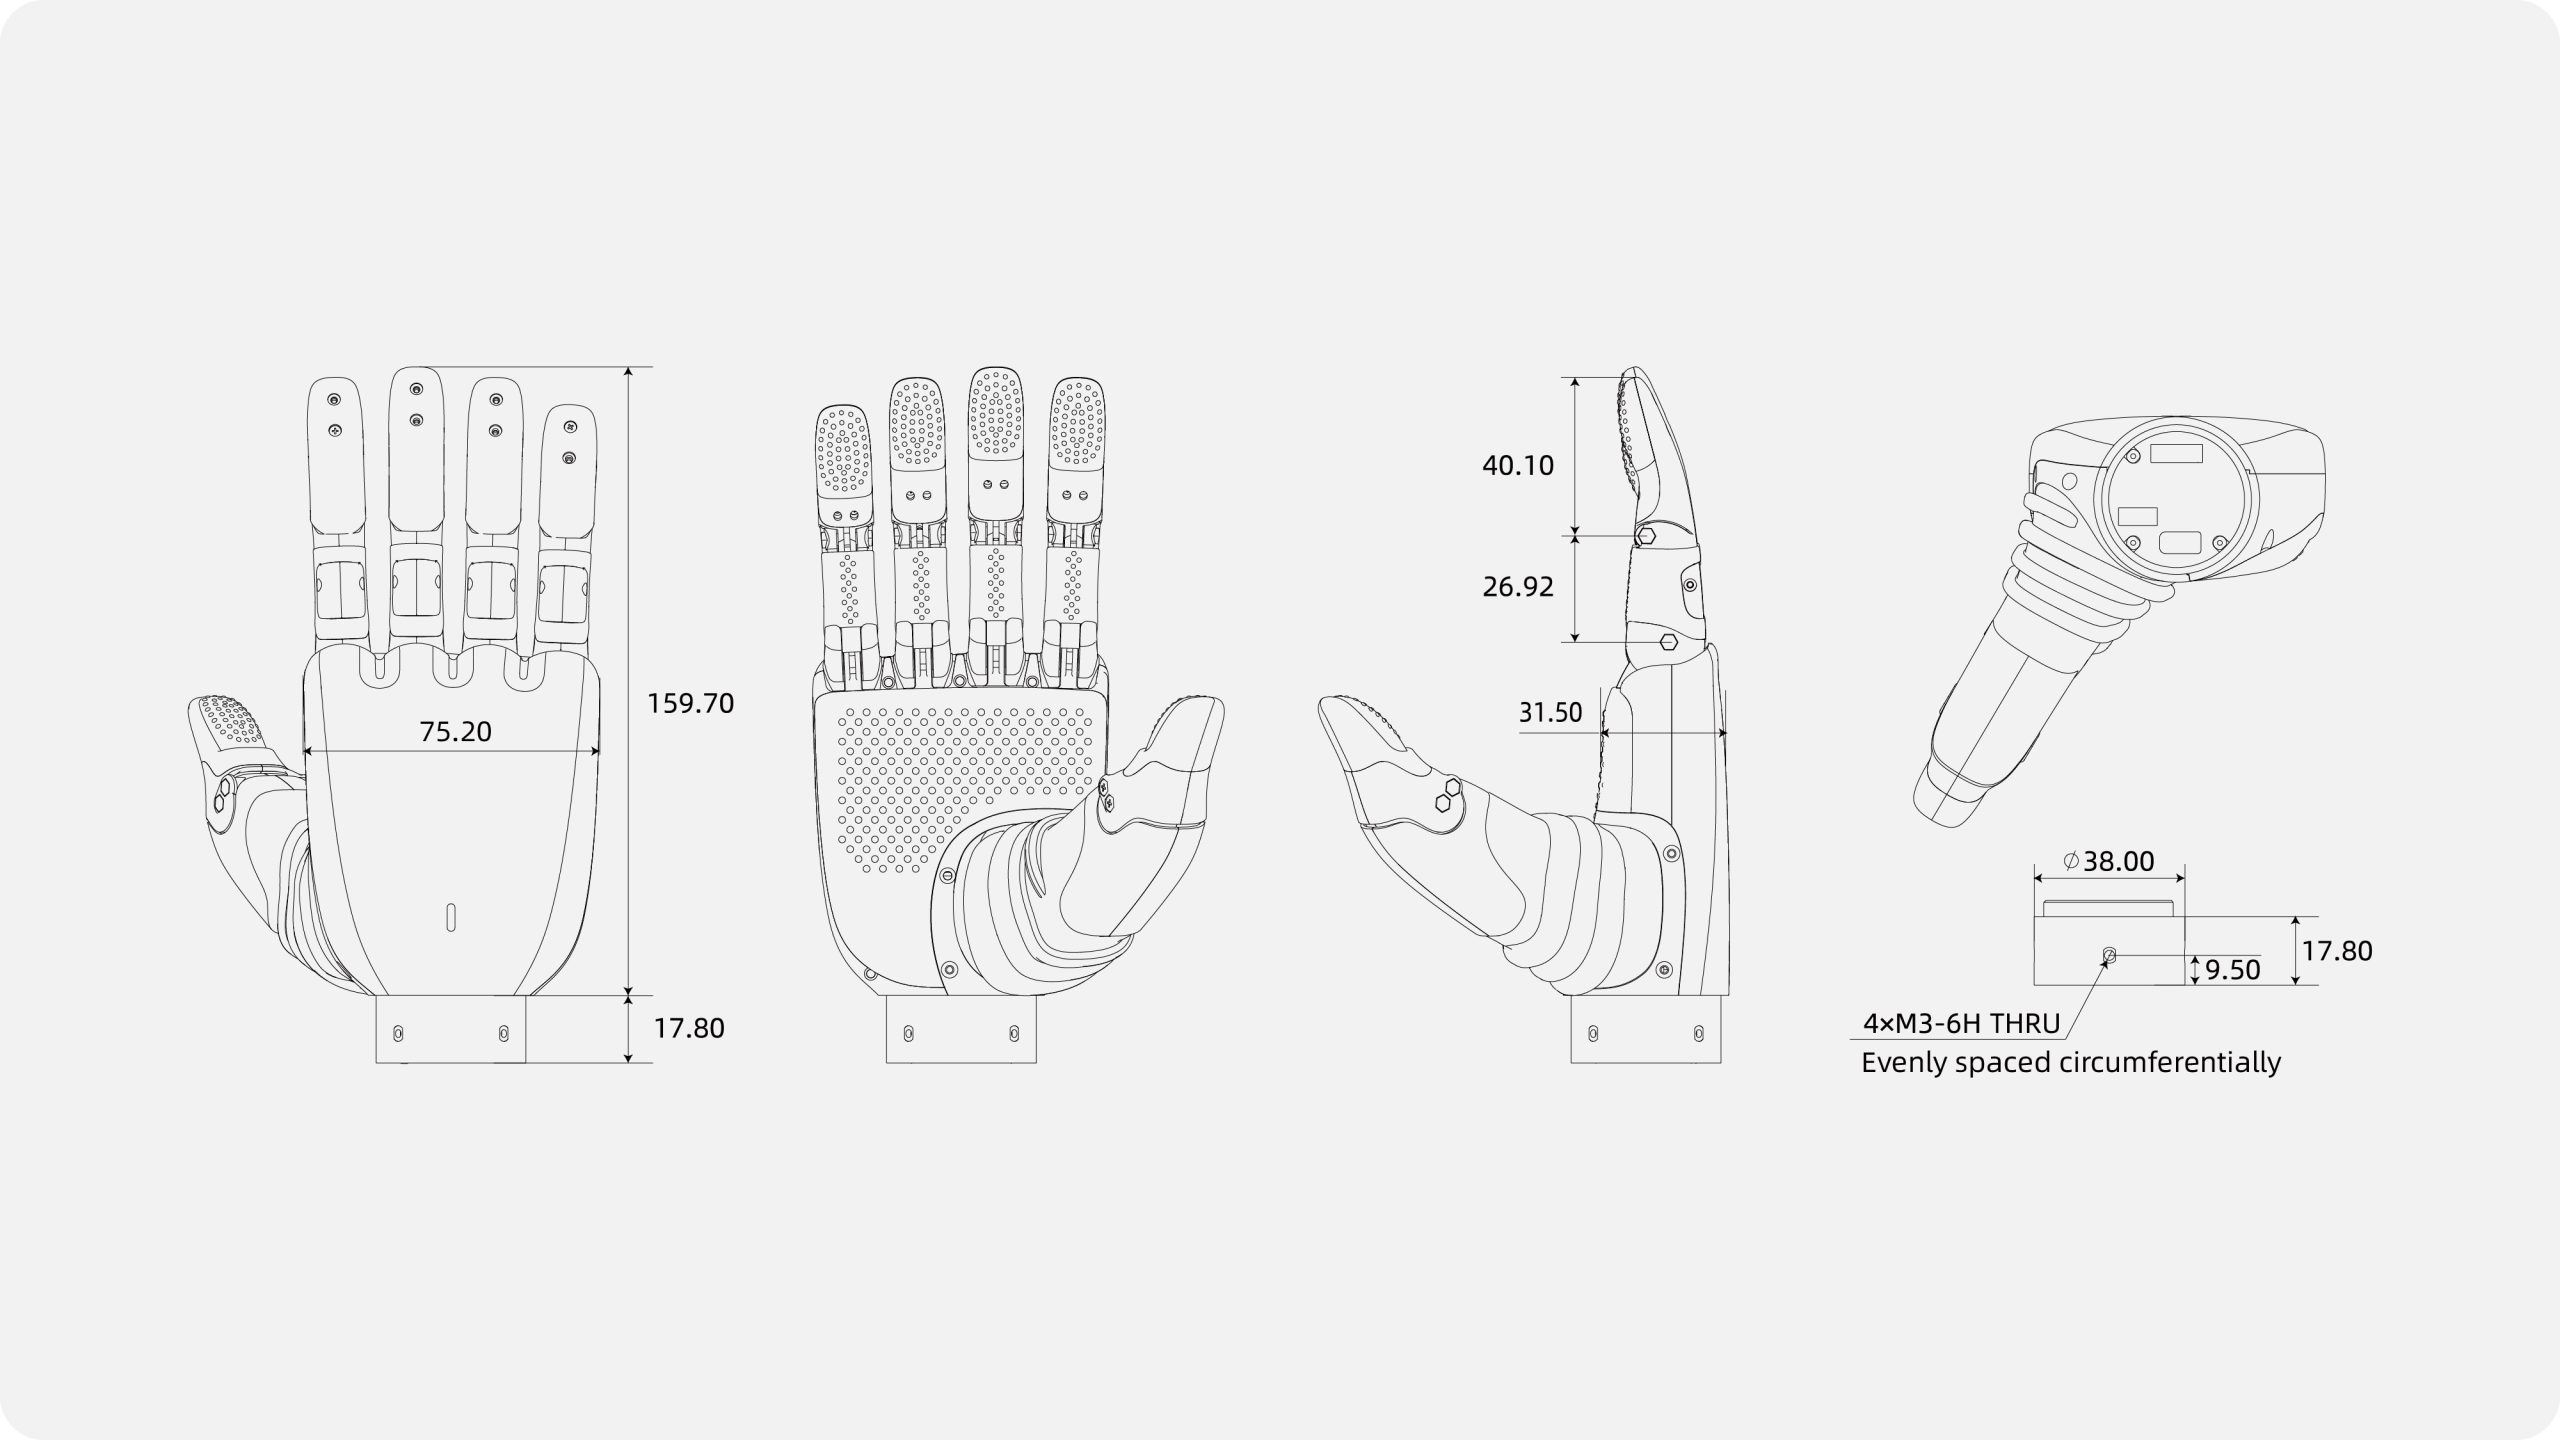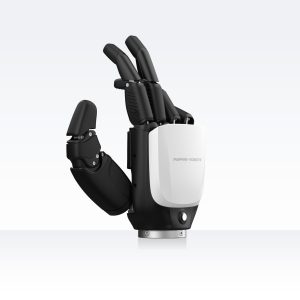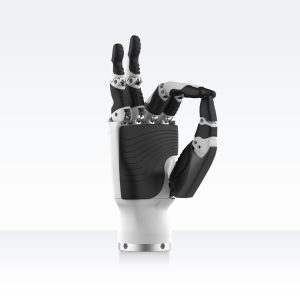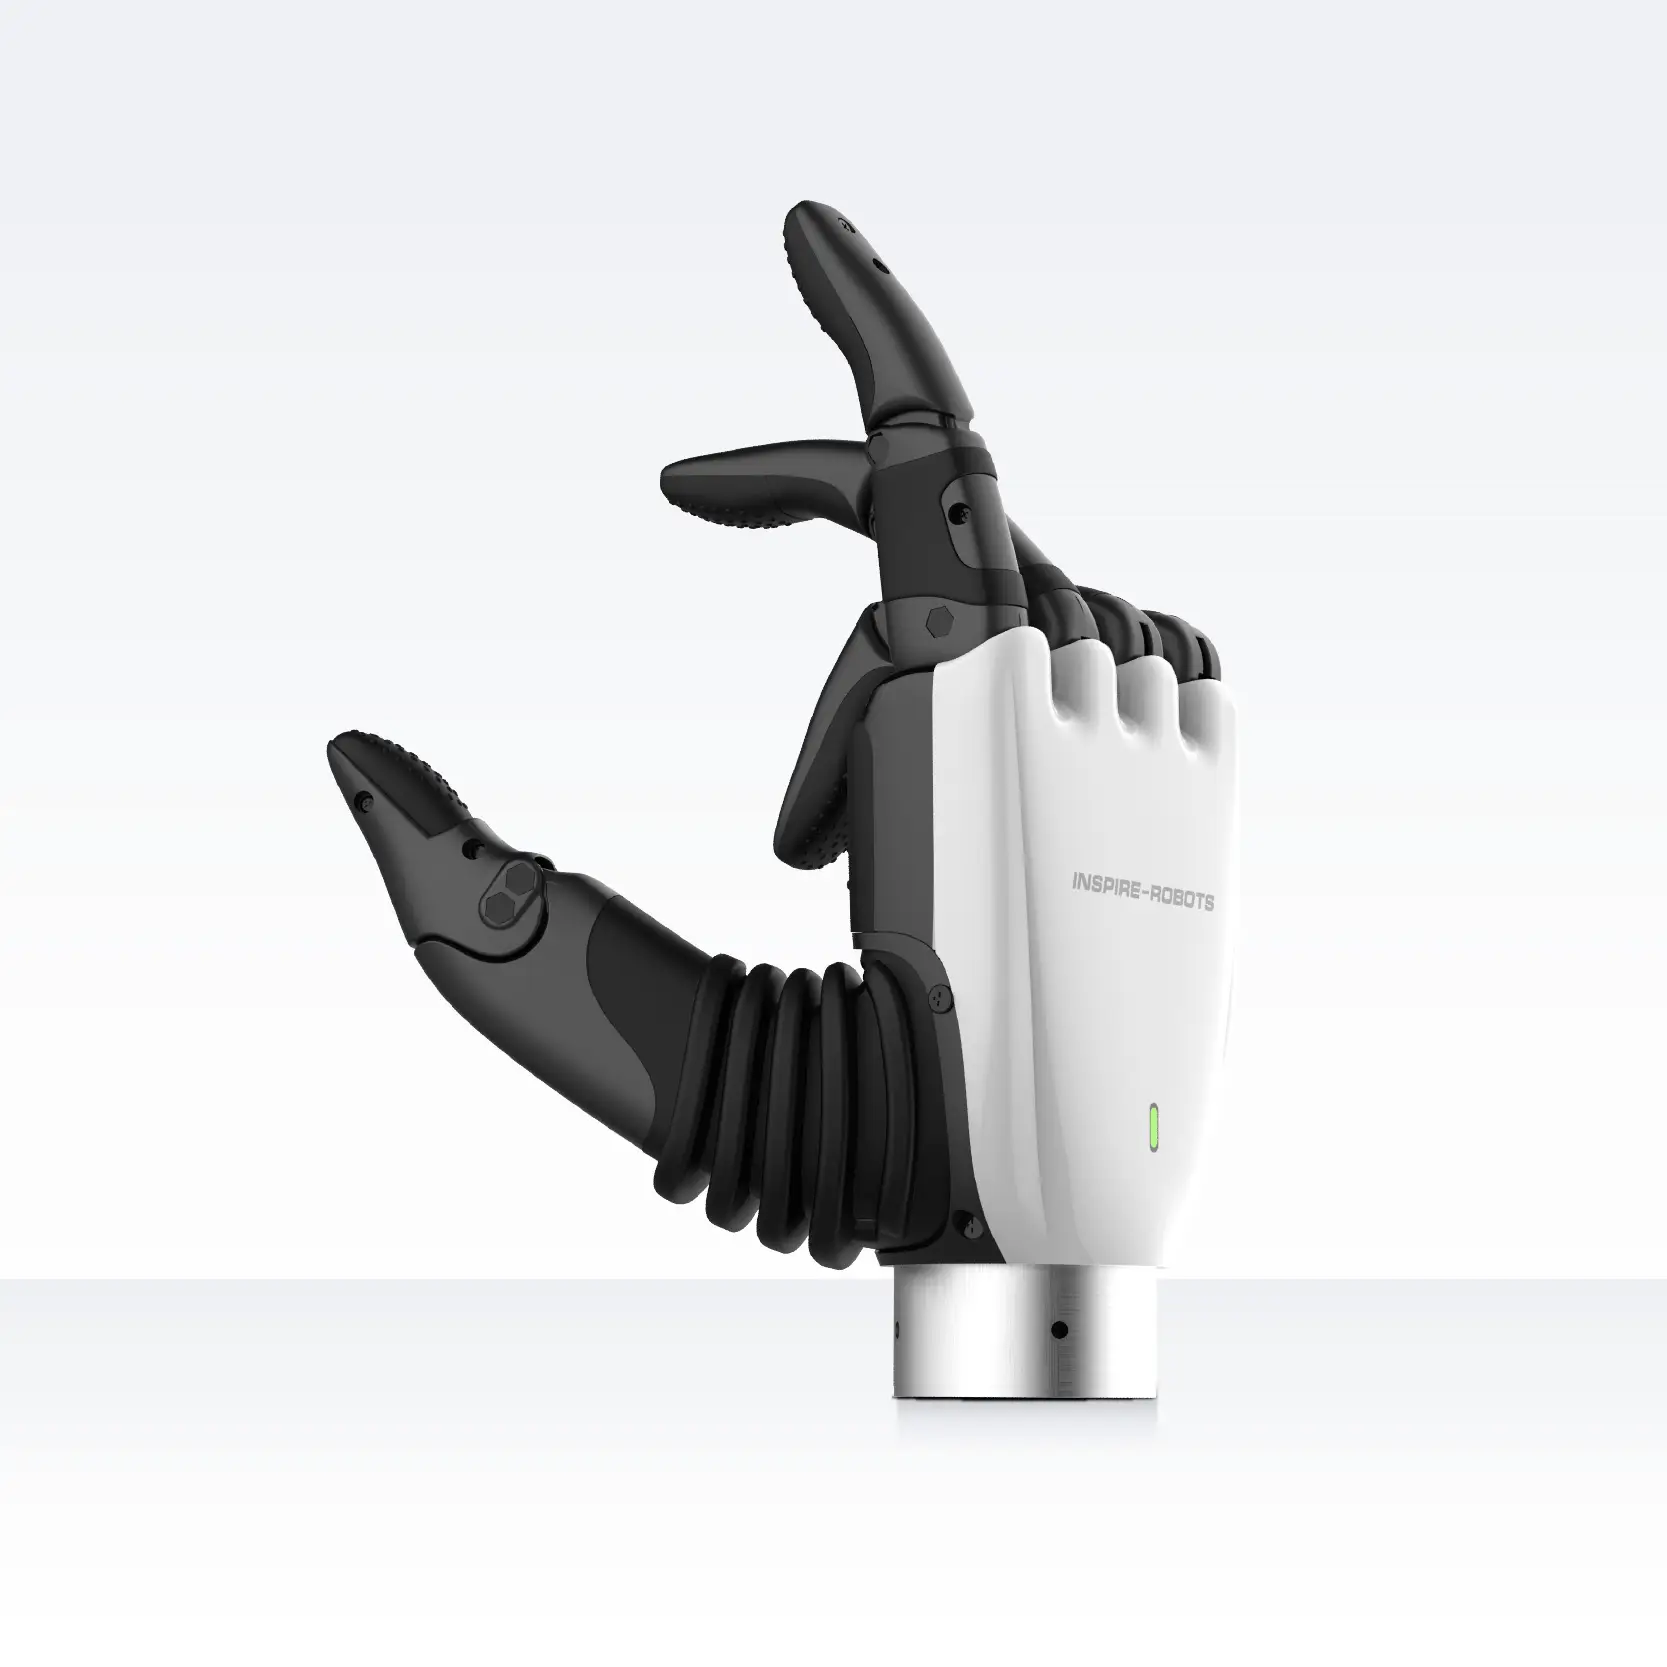
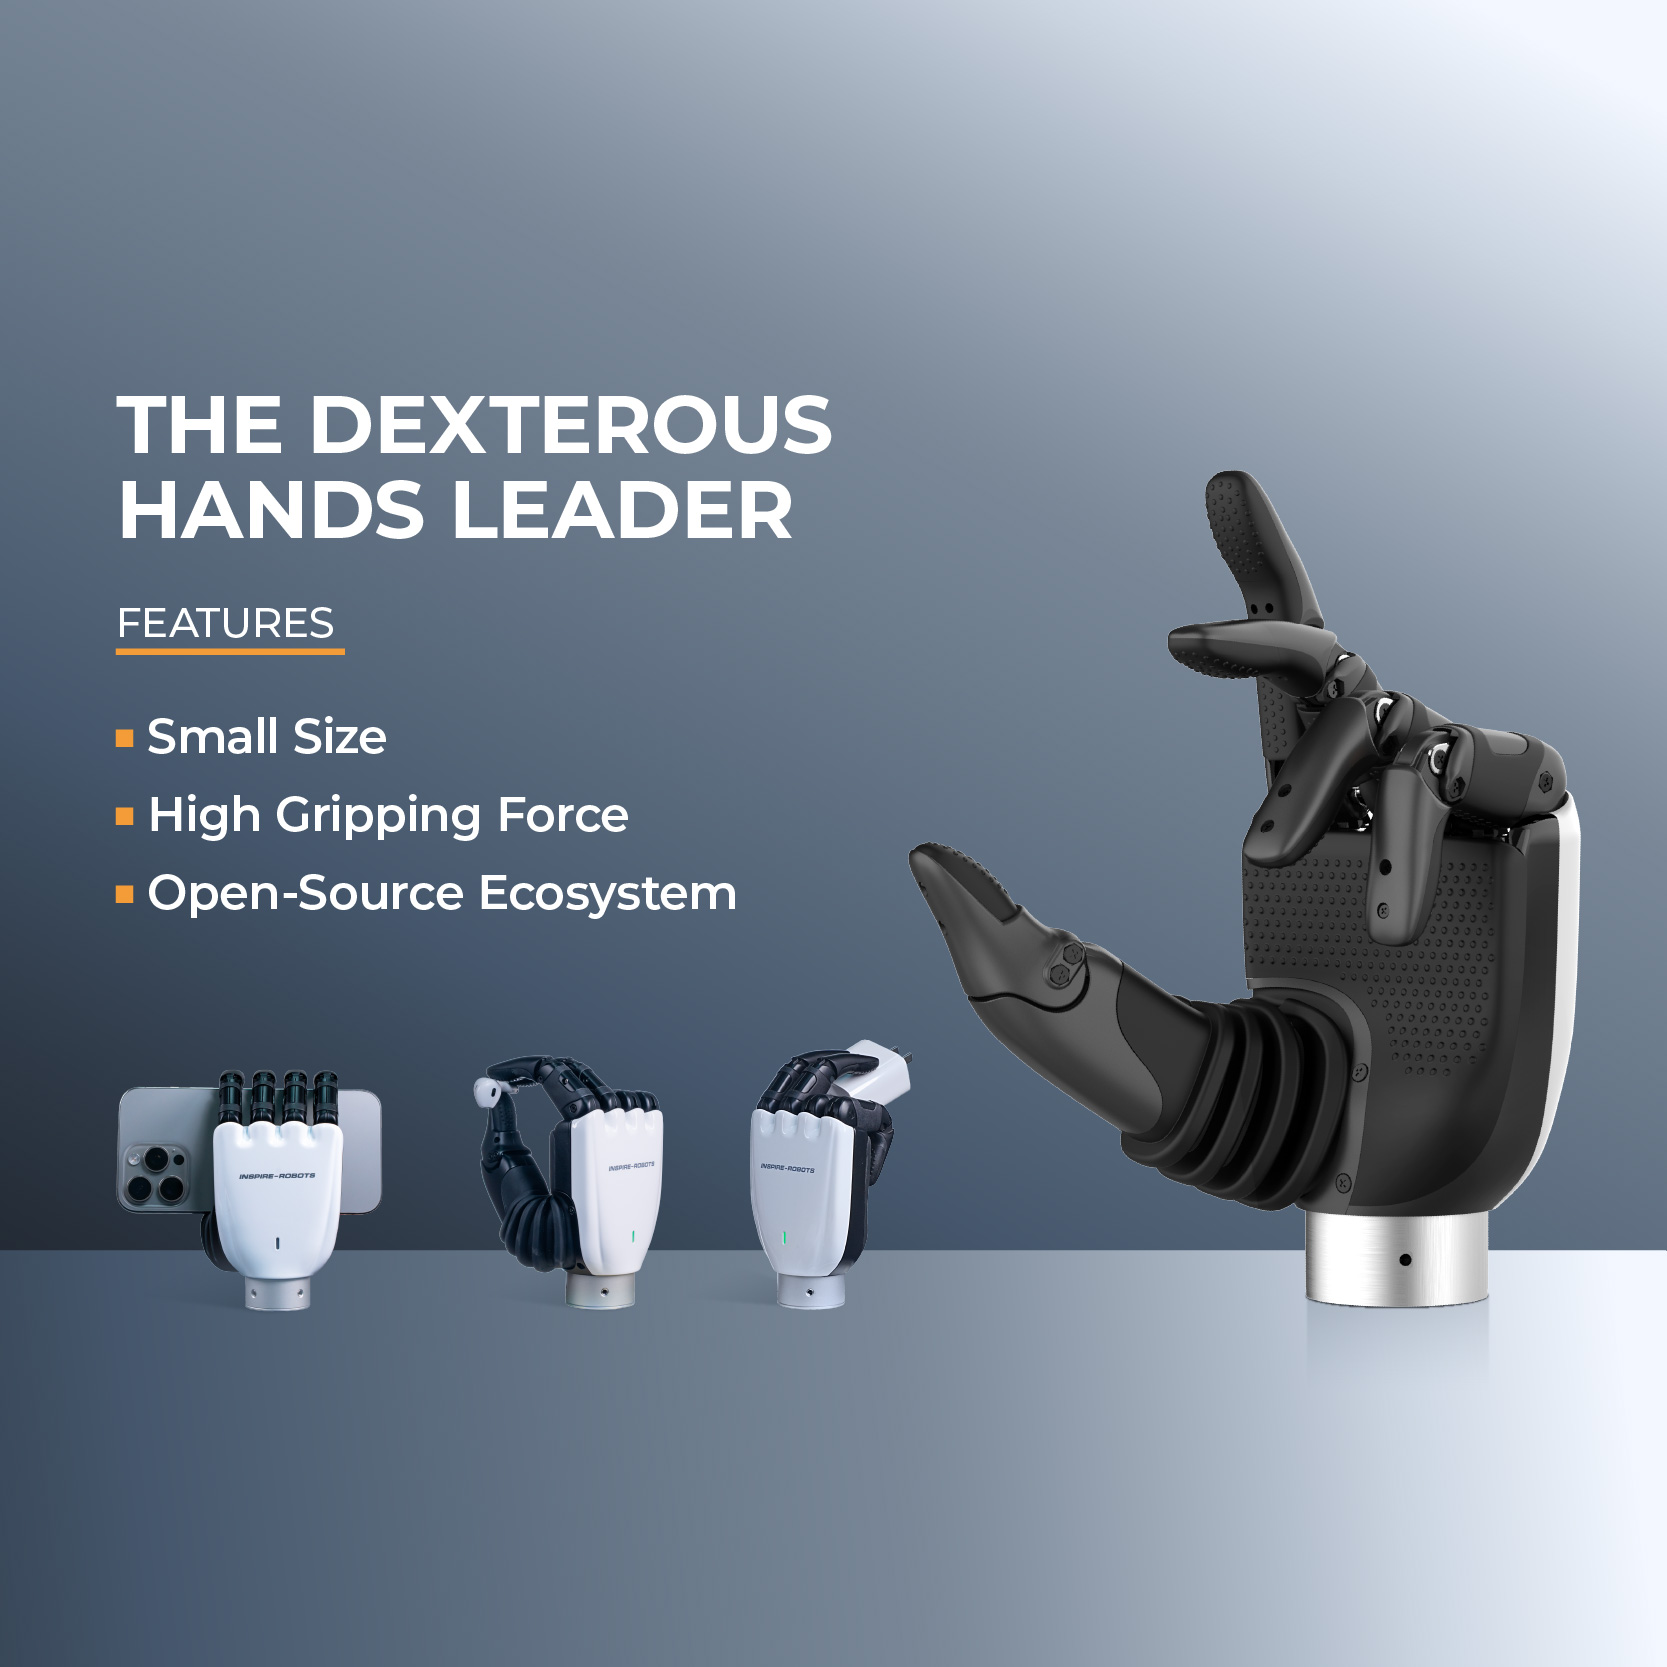
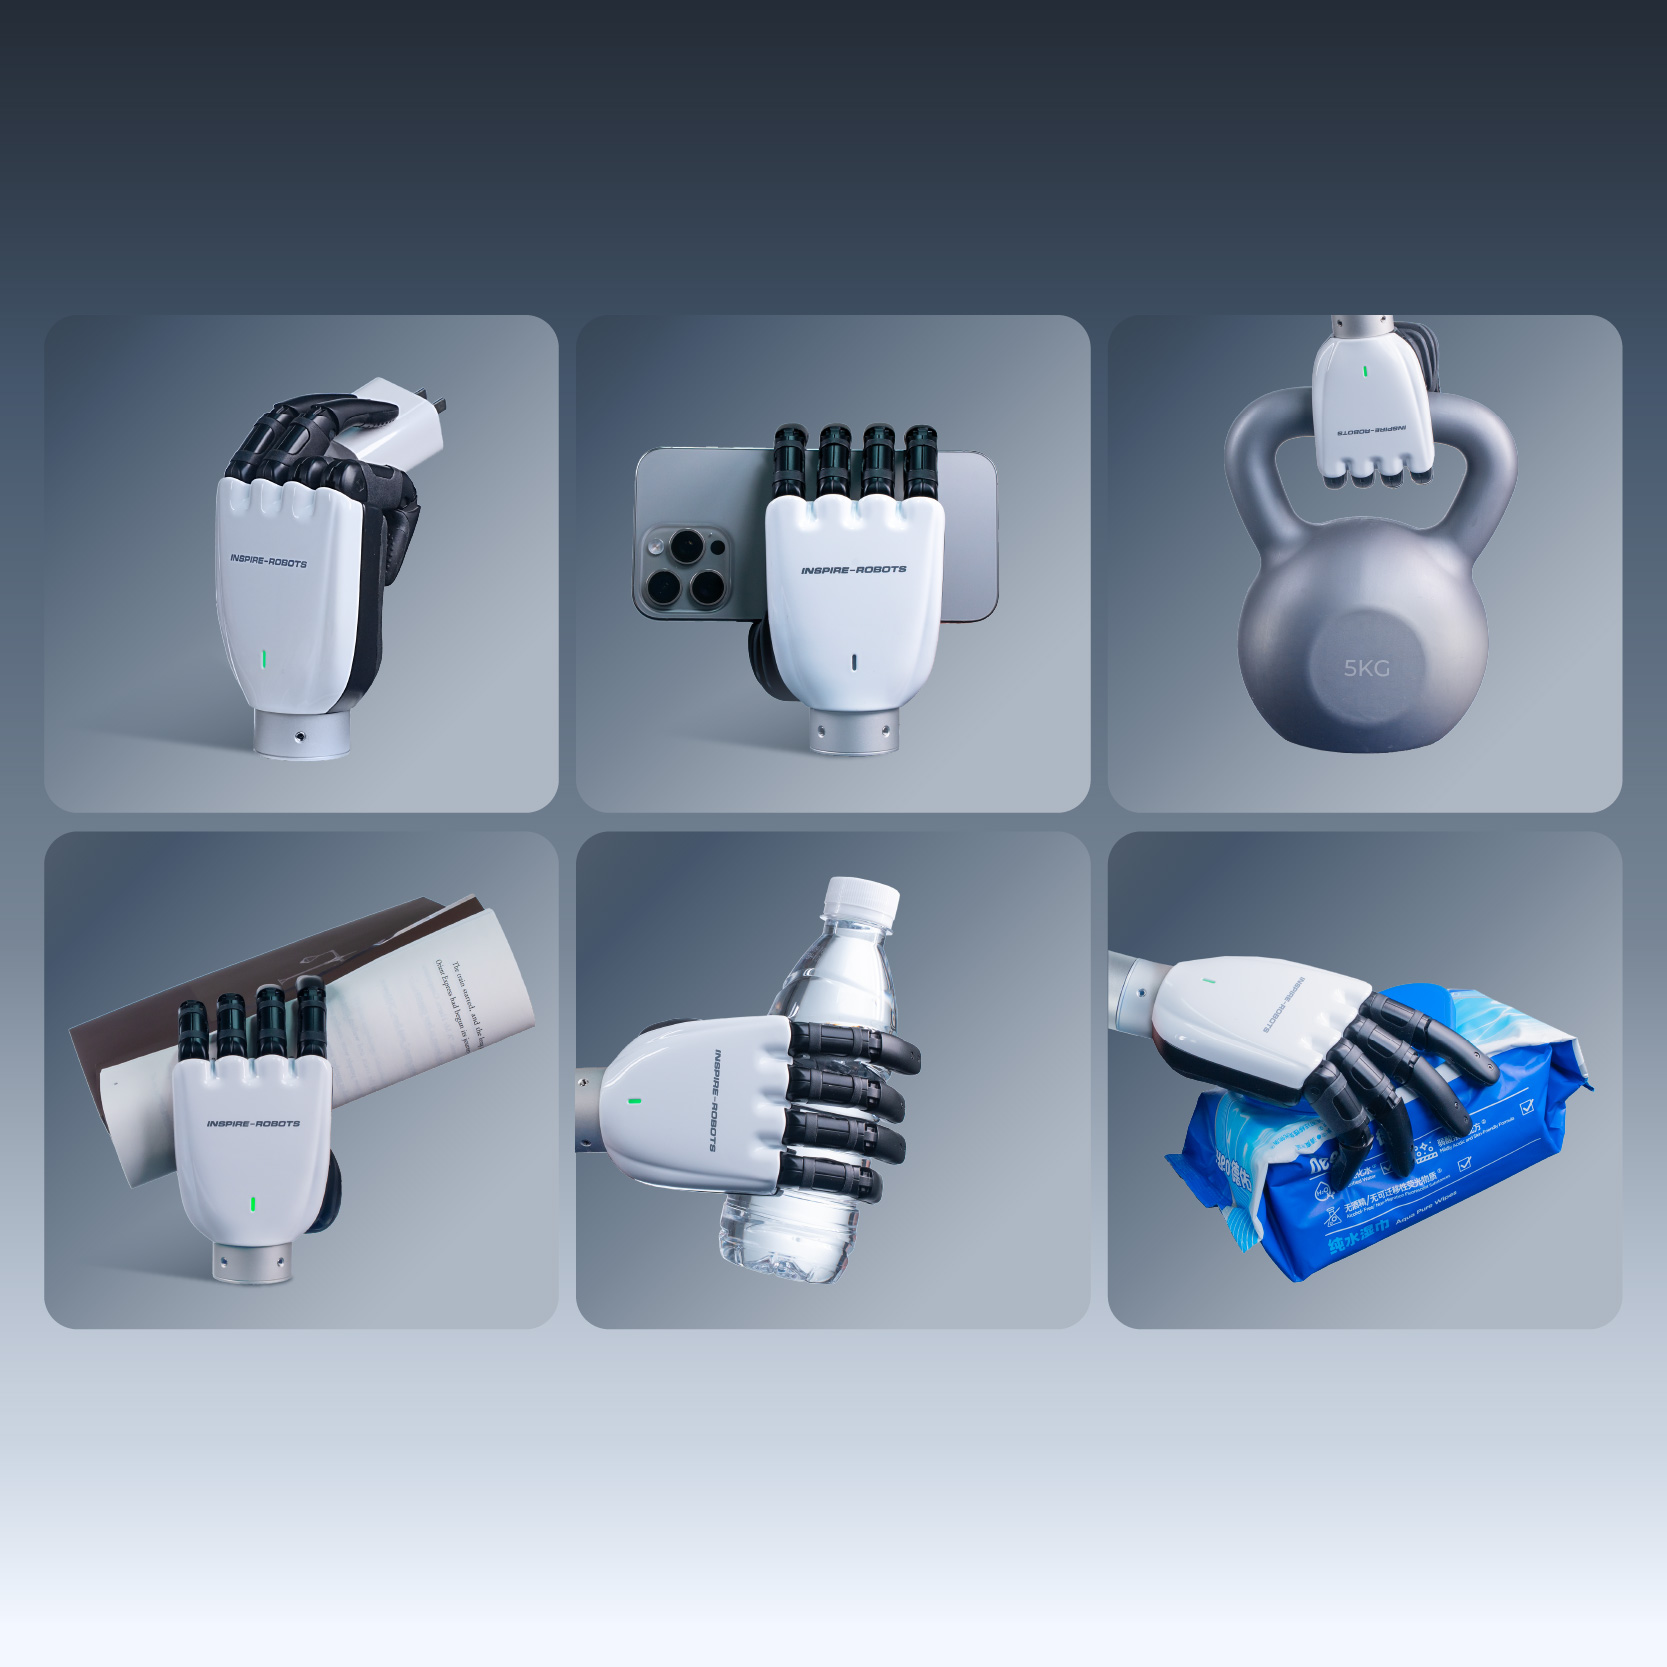
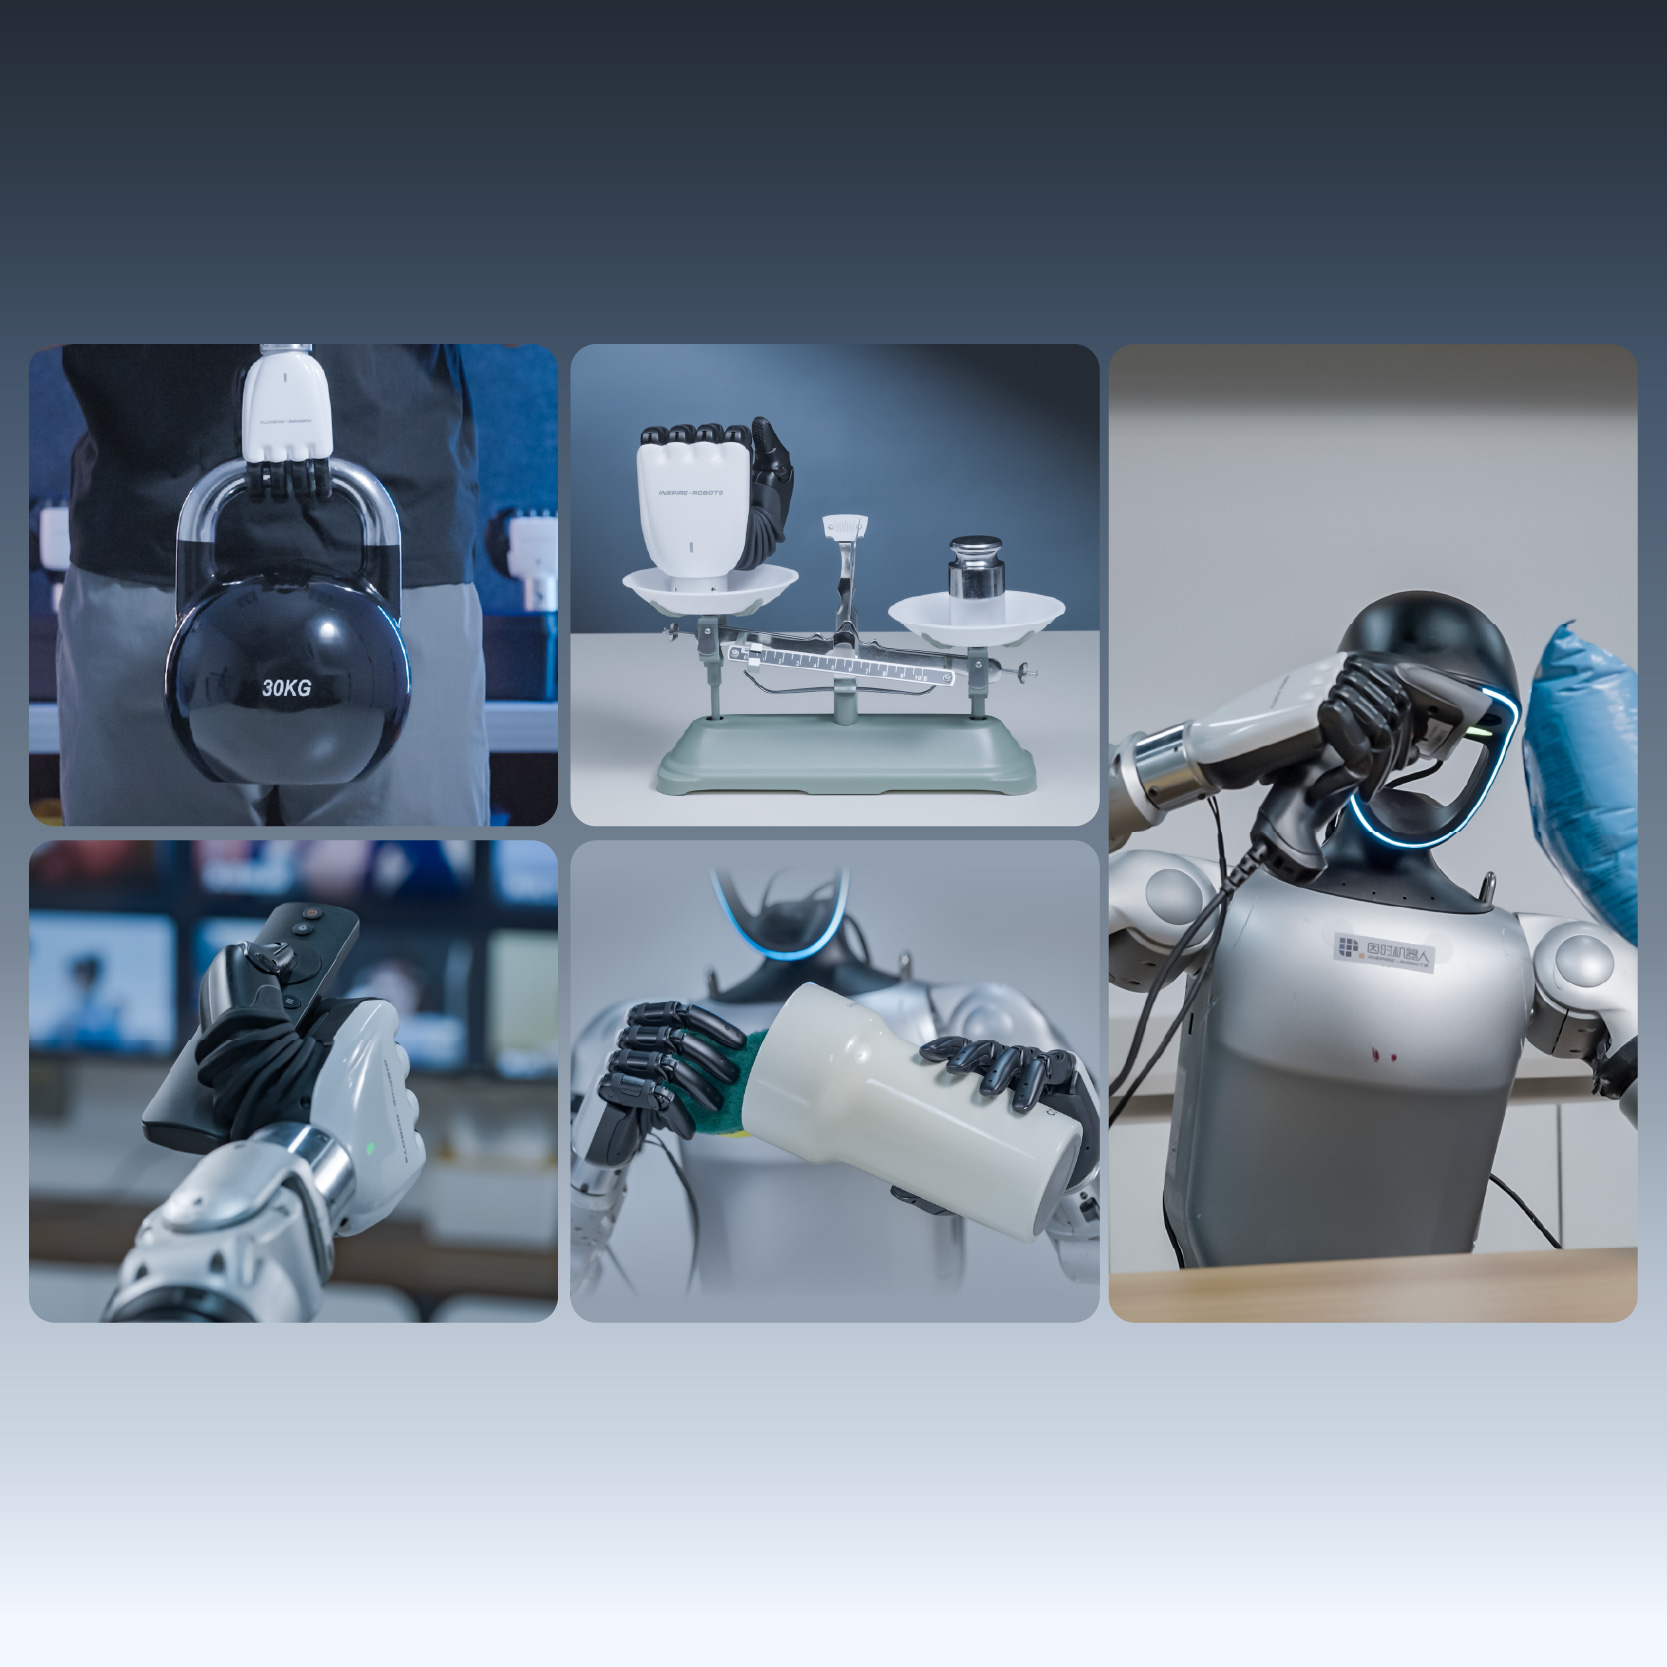
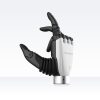
Compact dexterous hand featuring millisecond‑level high‑speed communication and complete open‑source development ecosystem
| Model | RH56H1‑42R‑T2 (Right hand model) RH56H1‑42L‑T2 (Left hand model)) | RH56H1‑E6R‑T2(Right) RH56H1‑E6L‑T2(Left) |
| Control interface | RS485+CANFD | EtherCAT+CAN-FD+RS485 |
| Degrees of freedom | 6 | 6 |
| Numbers of joints | 11 | 11 |
| Weight | 470±10g | 470±10g |
| Operating voltage | 24V~60V | 24V~60V |
| Quiescent current | 160mA±20mA@24V | 160mA±20mA@24V |
| Peak current | 5A @24V | 5A @24V |
| Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Strength | ≥15N | ≥15N |
| Fingertip Strength | ≥10N | ≥10N |
| Force resolution | 0.1N | 0.1N |
| Lateral rotation range of thumb | 70-170° | 70-170° |
| Lateral rotation speed of thumb | >157°/s | >157°/s |
| Flexion speed of thumb | >65°/s | >65°/s |
| Flexion speed of four finger | >110°/s | >110°/s |
| Range of tactile sensor | 30N | 30N |
| Tactile sensor accuracy | 5%FS | 5%FS |
| Number of tactile sensors | 6 | 6 |
| Hand closing time | ≤0.8s | ≤0.8s |
| Model | RH56H1-42R(Right hand model) | RH56H1-42L(Left hand model) |
| Control interface | RS485+CANFD | RS485+CANFD |
| Degrees of freedom | 6 | 6 |
| Numbers of joints | 11 | 11 |
| Weight | 470±10g | 470±10g |
| Operating voltage | 24V~60V | 24V~60V |
| Quiescent current | 160mA±20mA@24V | 160mA±20mA@24V |
| Peak current | 5A @24V | 5A @24V |
| Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Strength | ≥15N | ≥15N |
| Fingertip Strength | ≥10N | ≥10N |
| Force resolution | 0.1N | 0.1N |
| Lateral rotation range of thumb | 70-170° | 70-170° |
| Lateral rotation speed of thumb | >157°/s | >157°/s |
| Flexion speed of thumb | >65°/s | >65°/s |
| Flexion speed of four finger | >110°/s | >110°/s |
| Range of tactile sensor | / | / |
| Tactile sensor accuracy | / | / |
| Number of tactile sensors | / | / |
| Hand closing time | ≤0.8s | ≤0.8s |