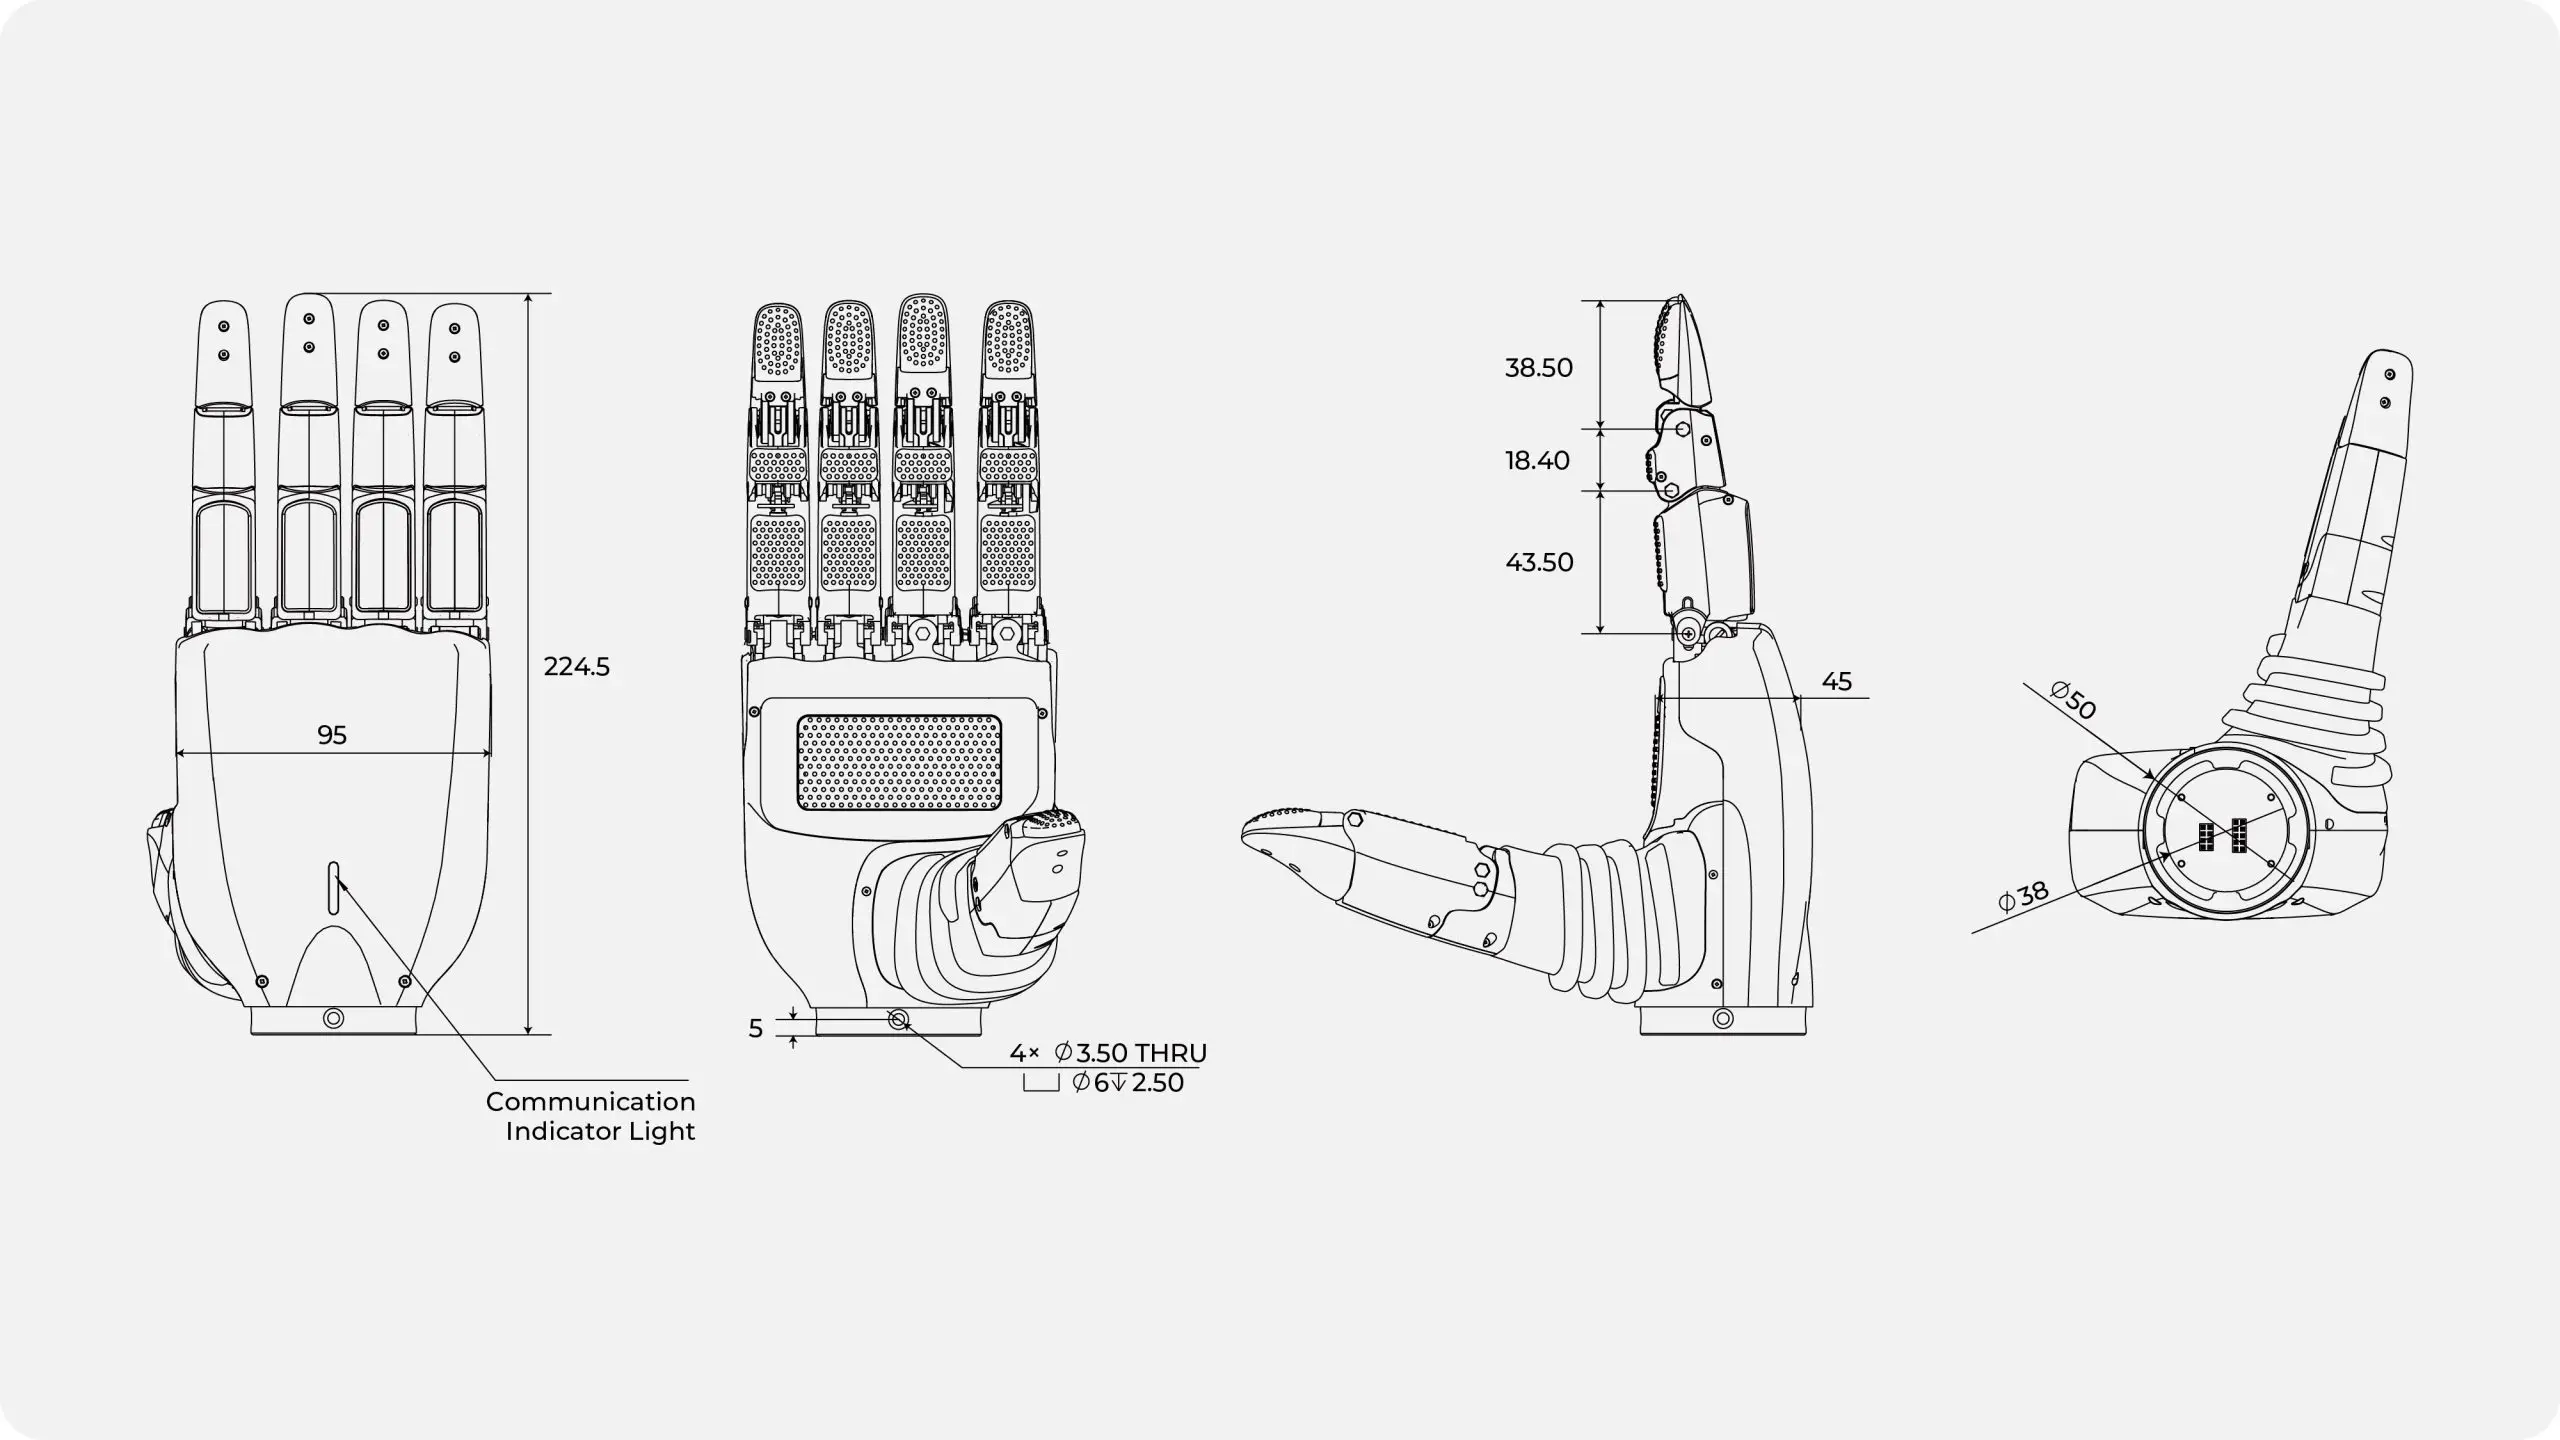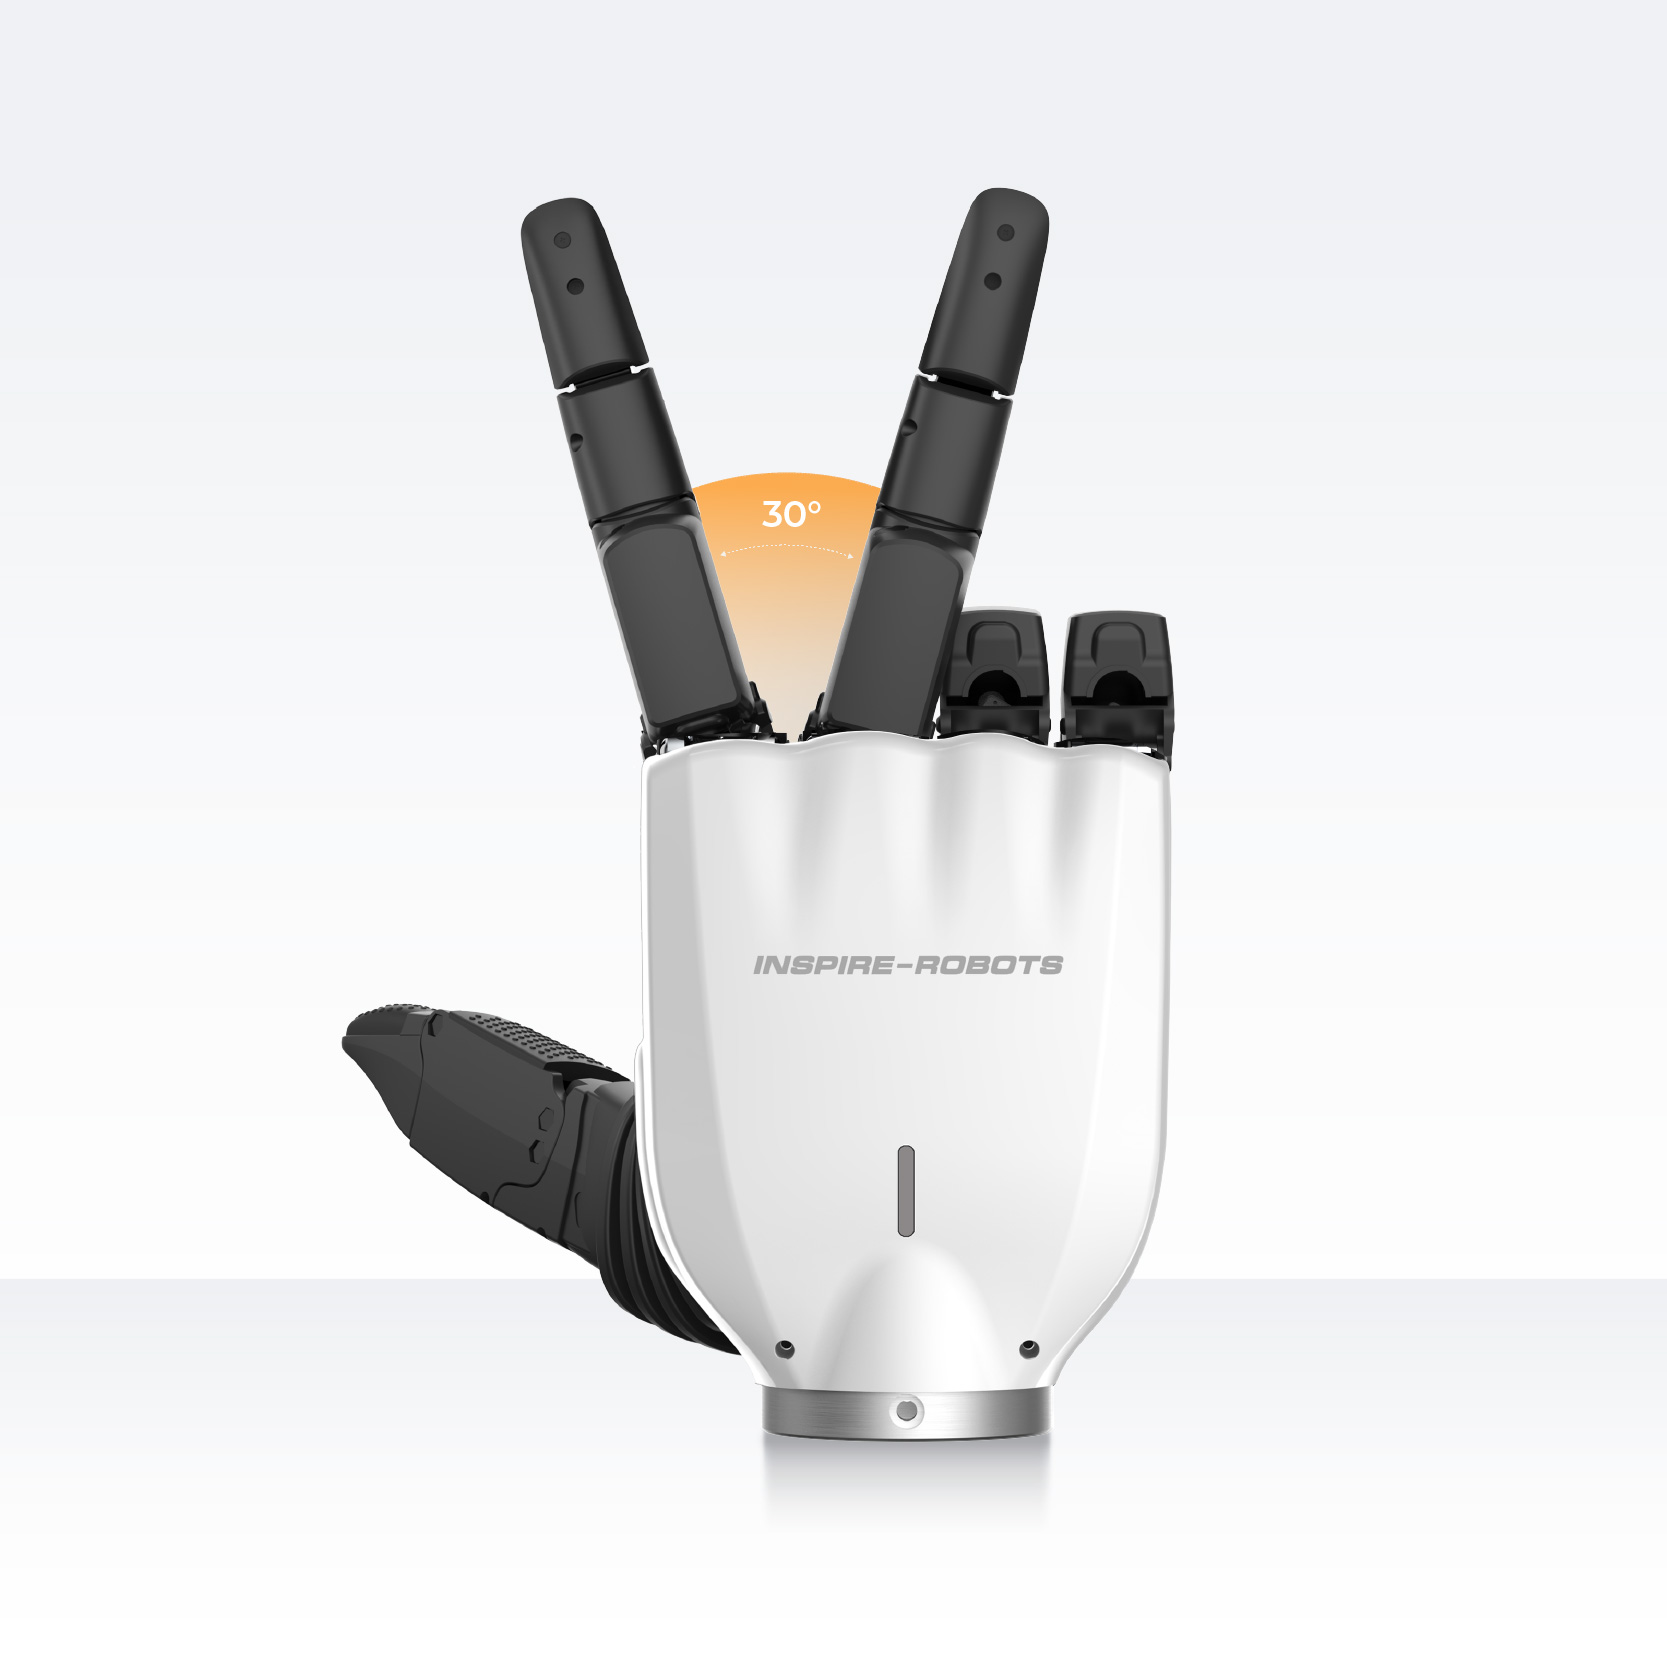
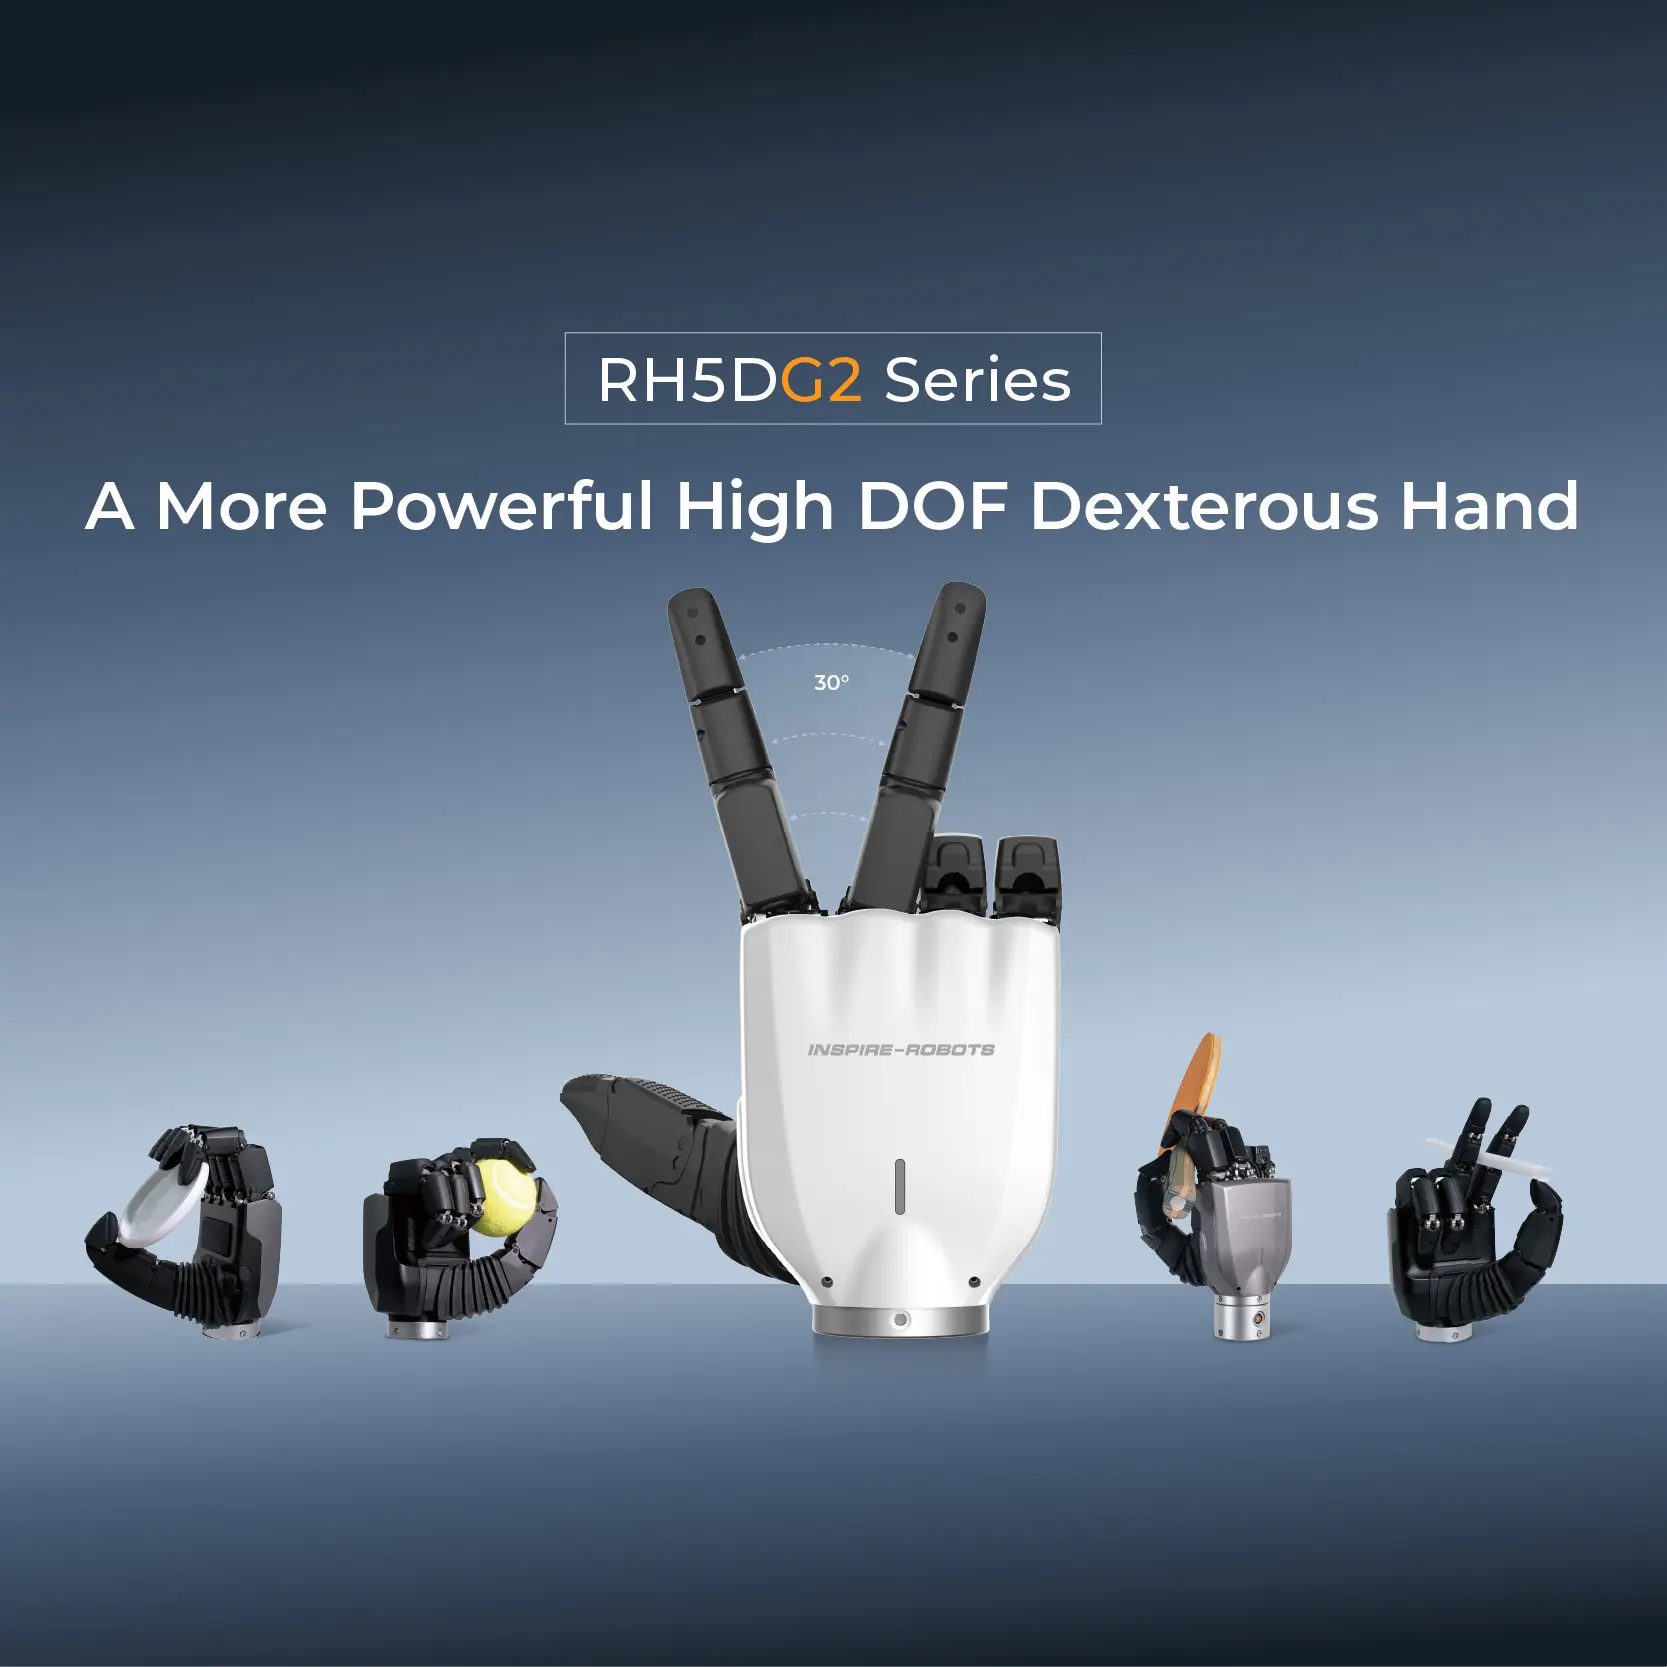
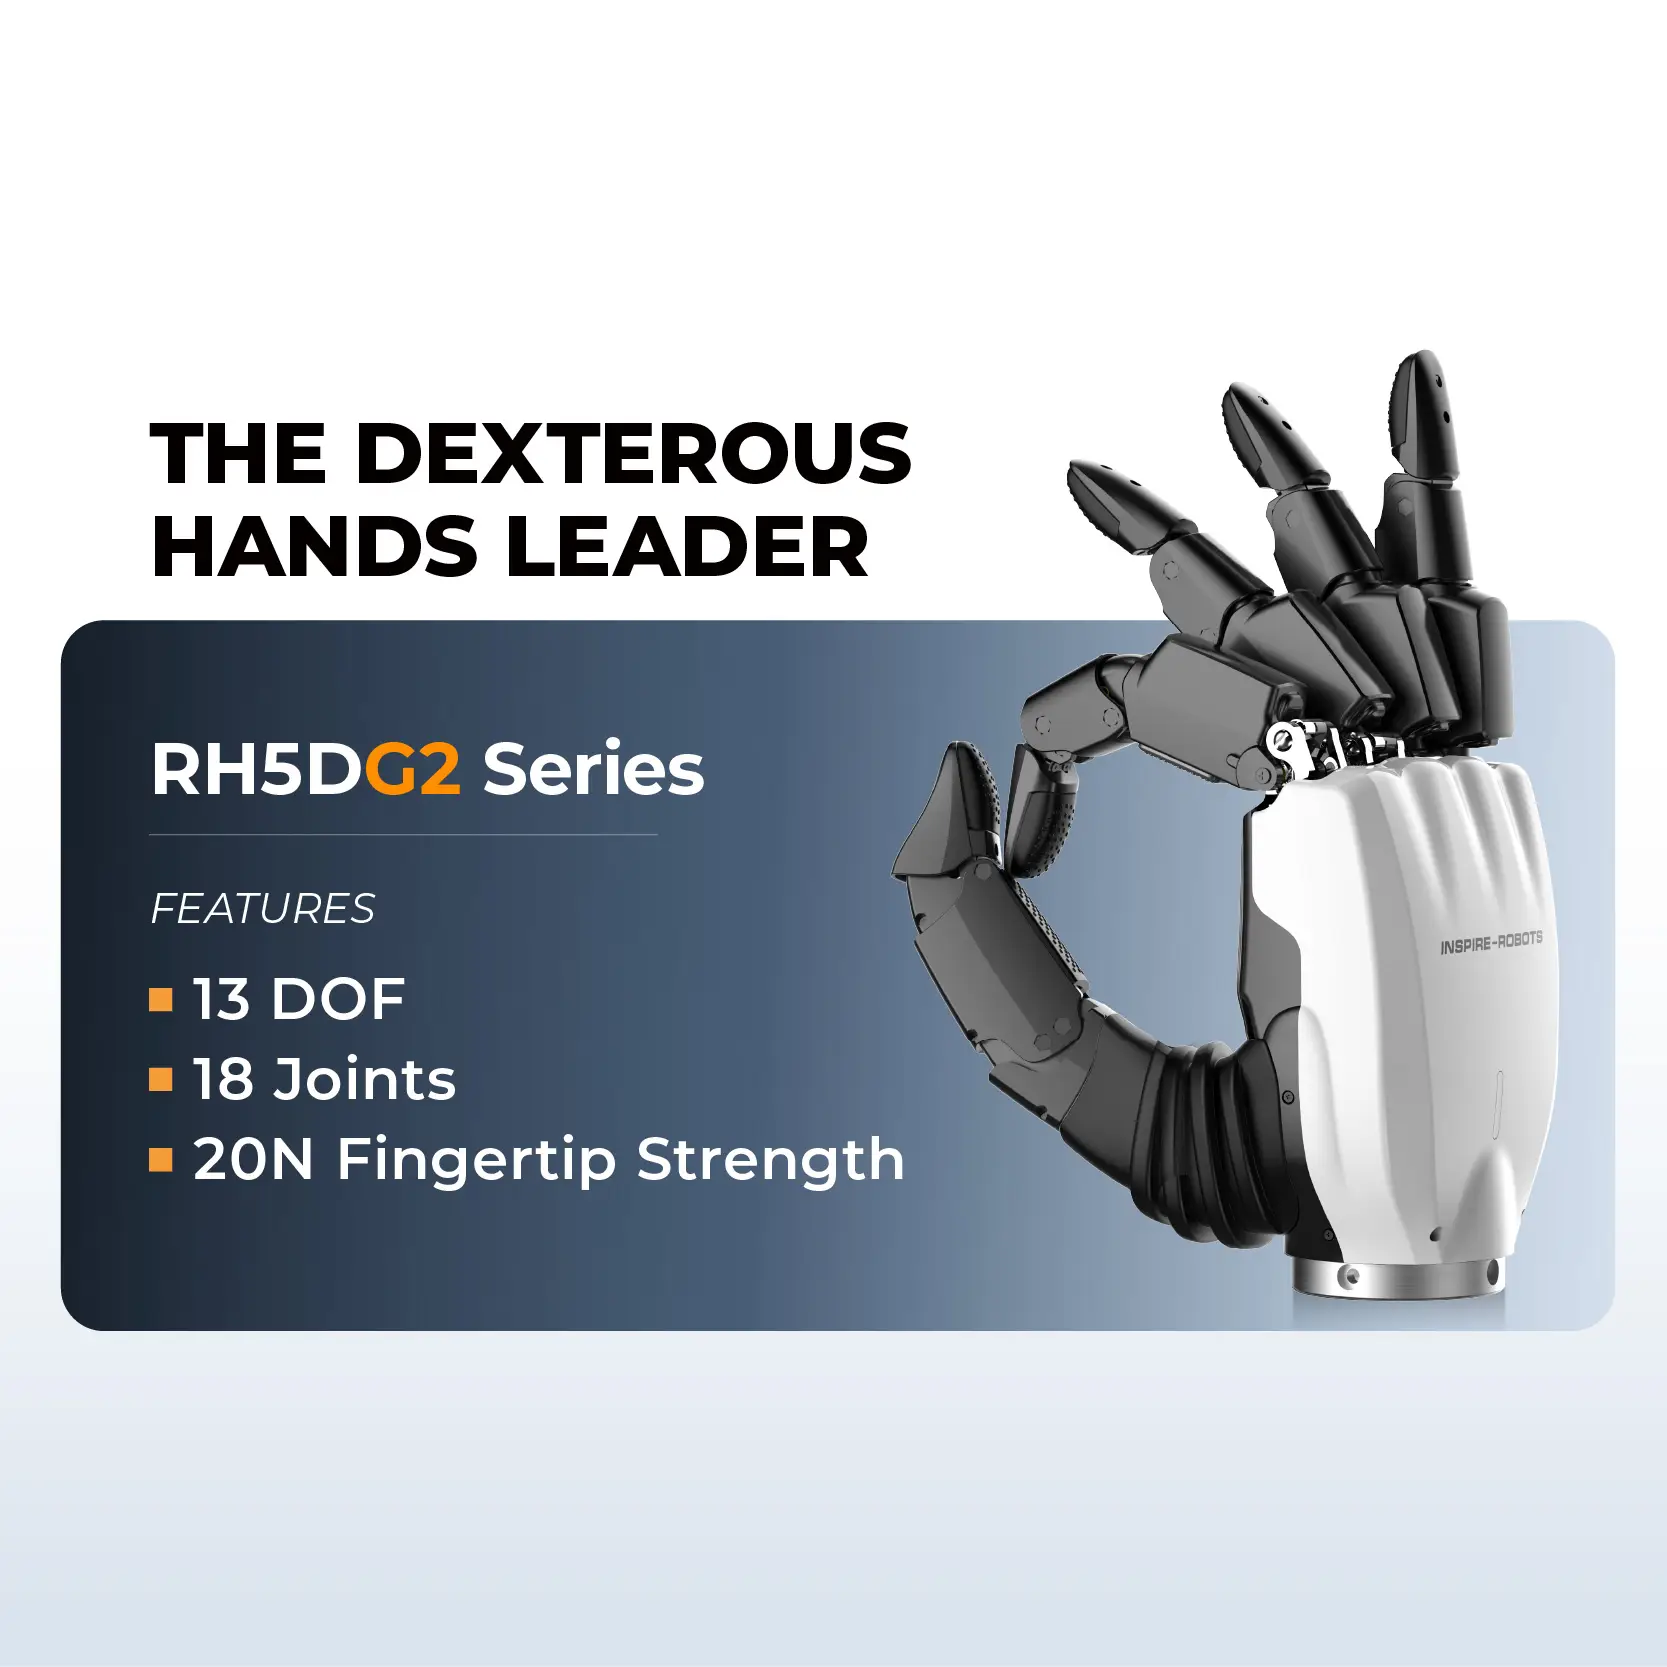
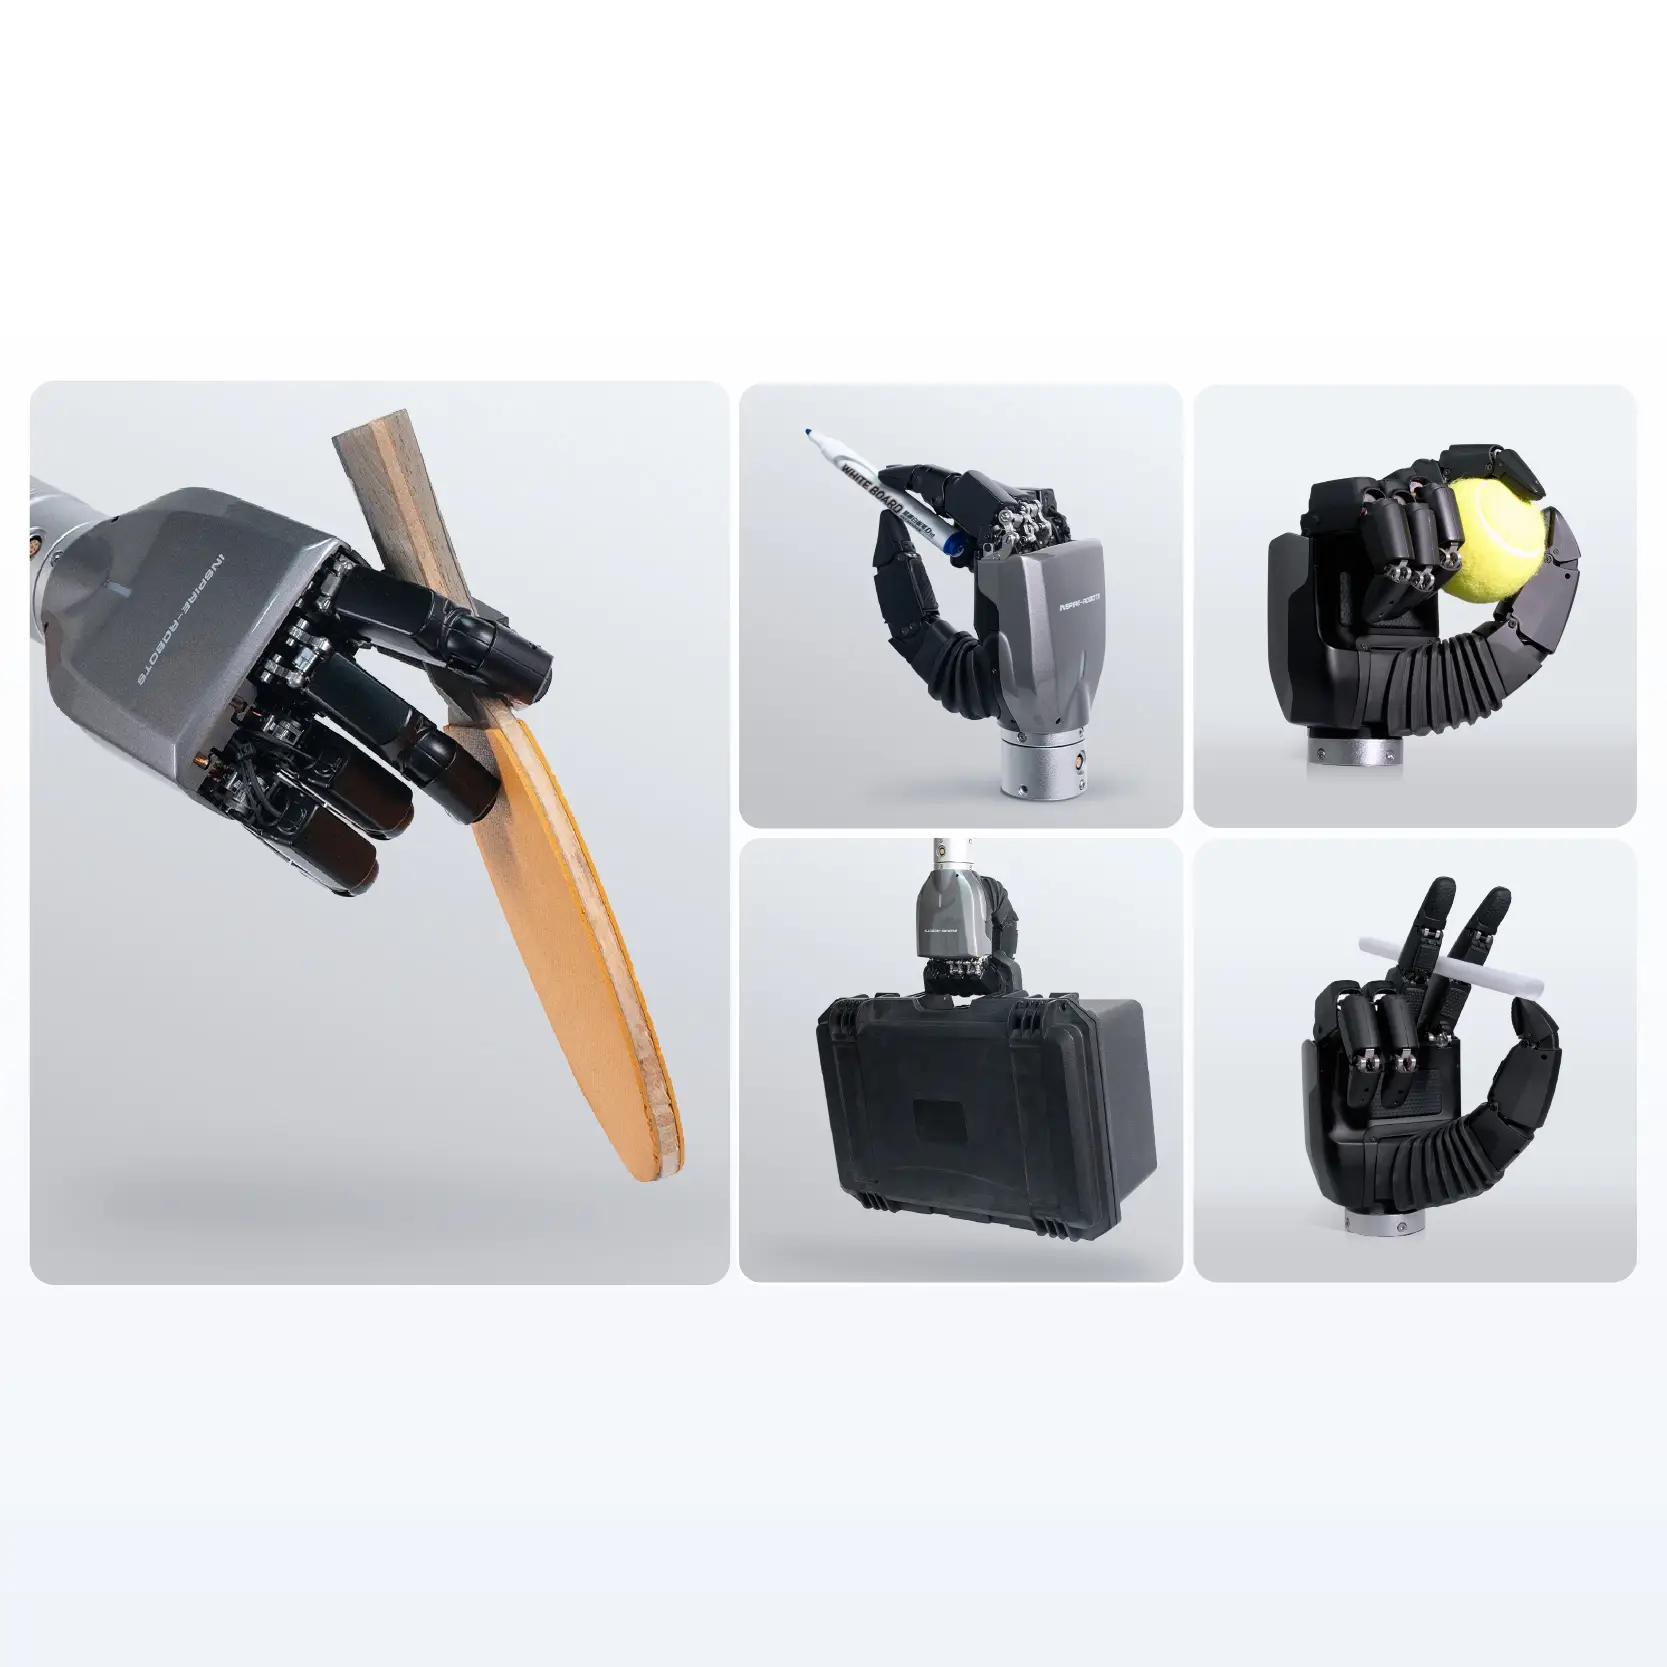
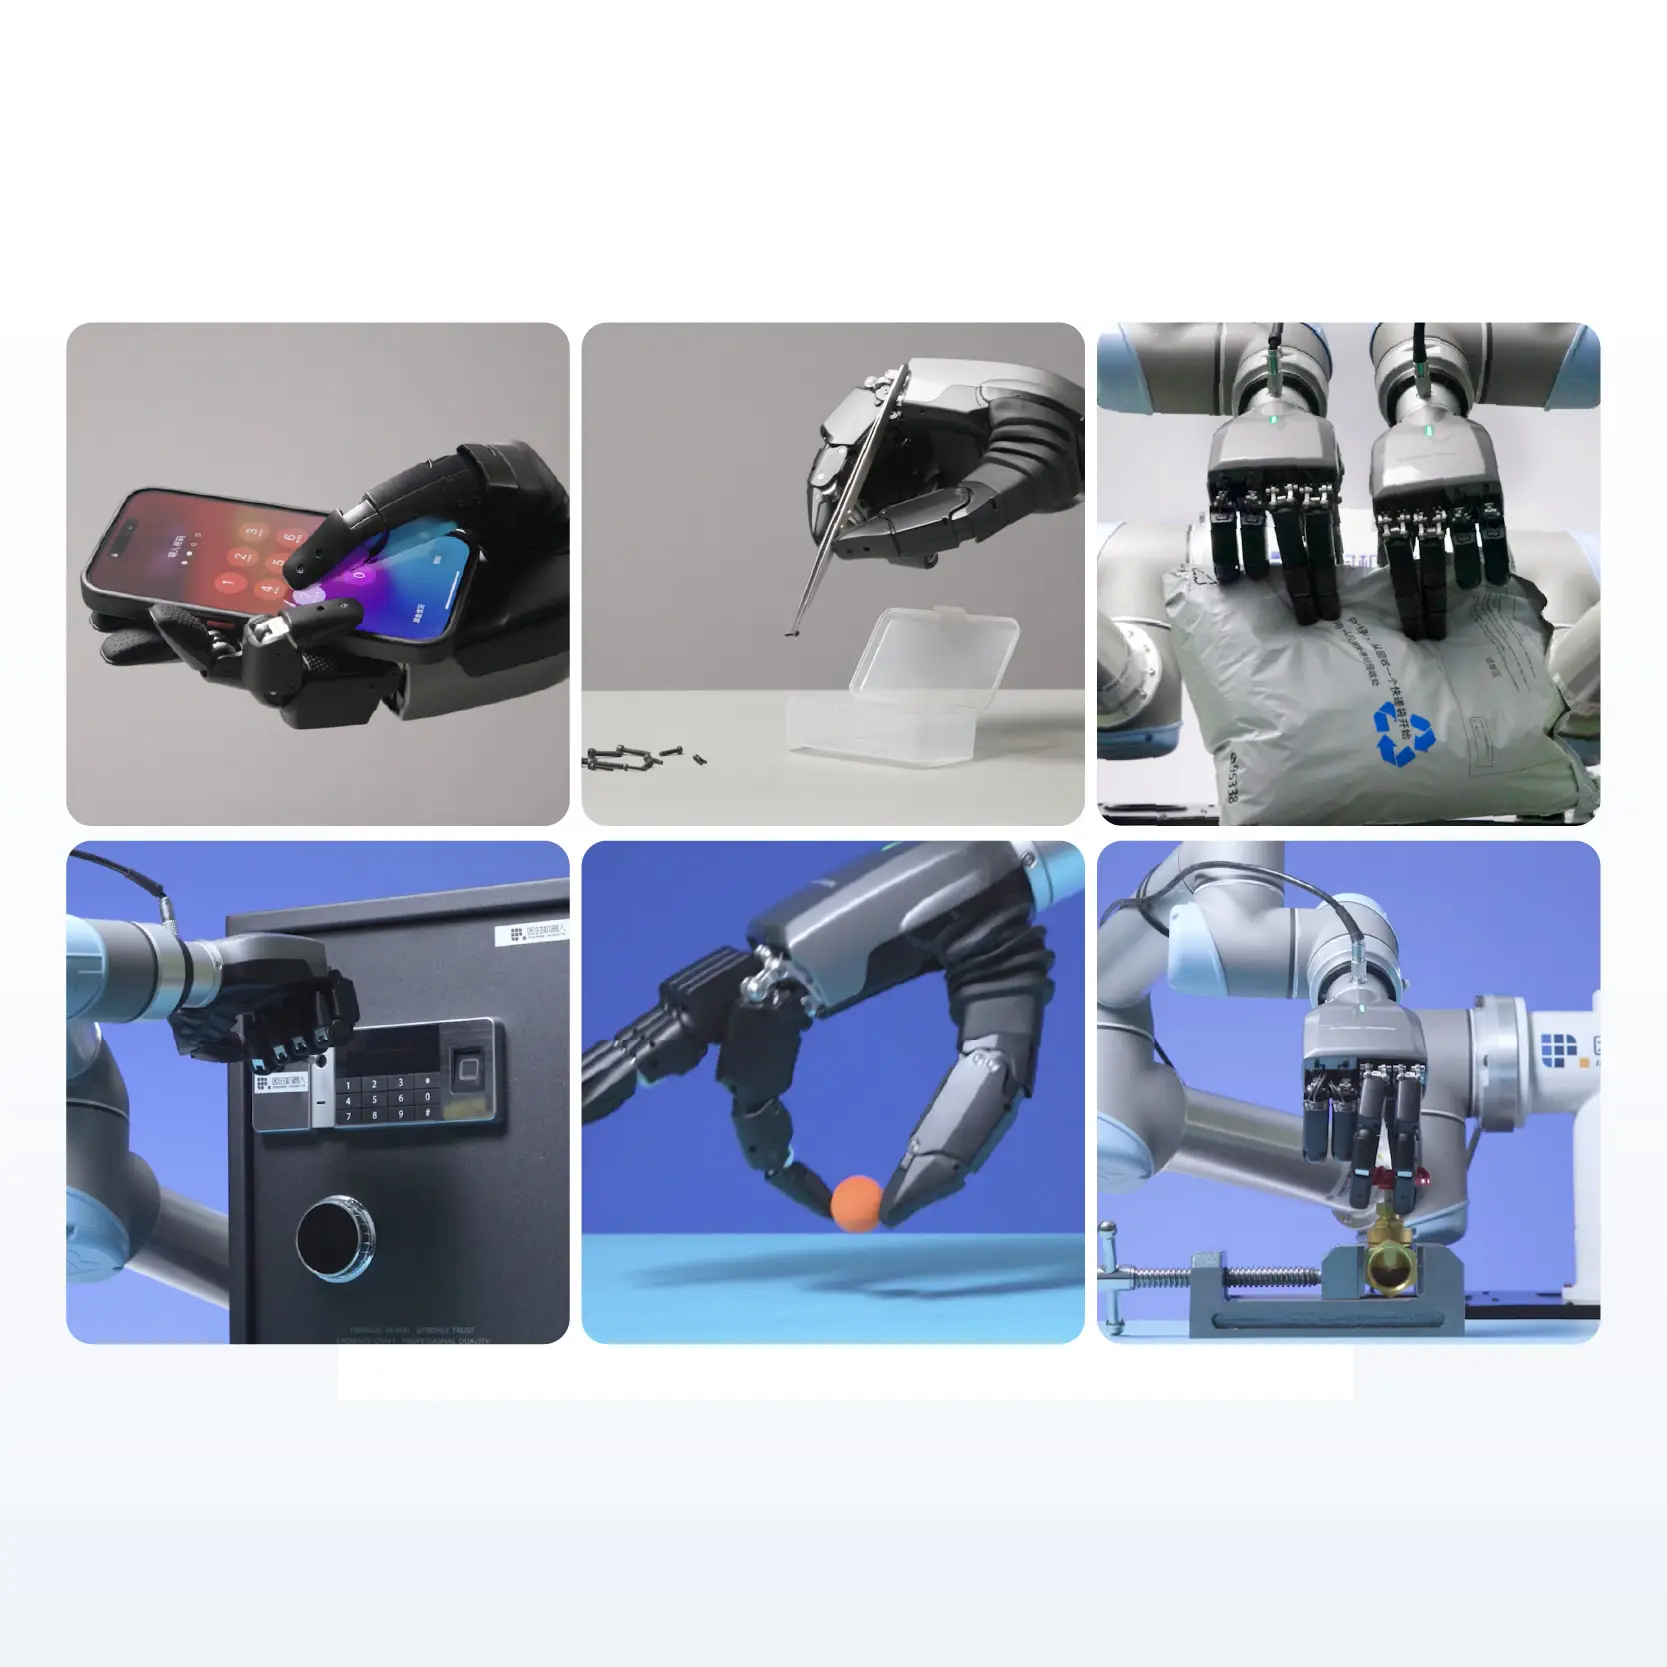
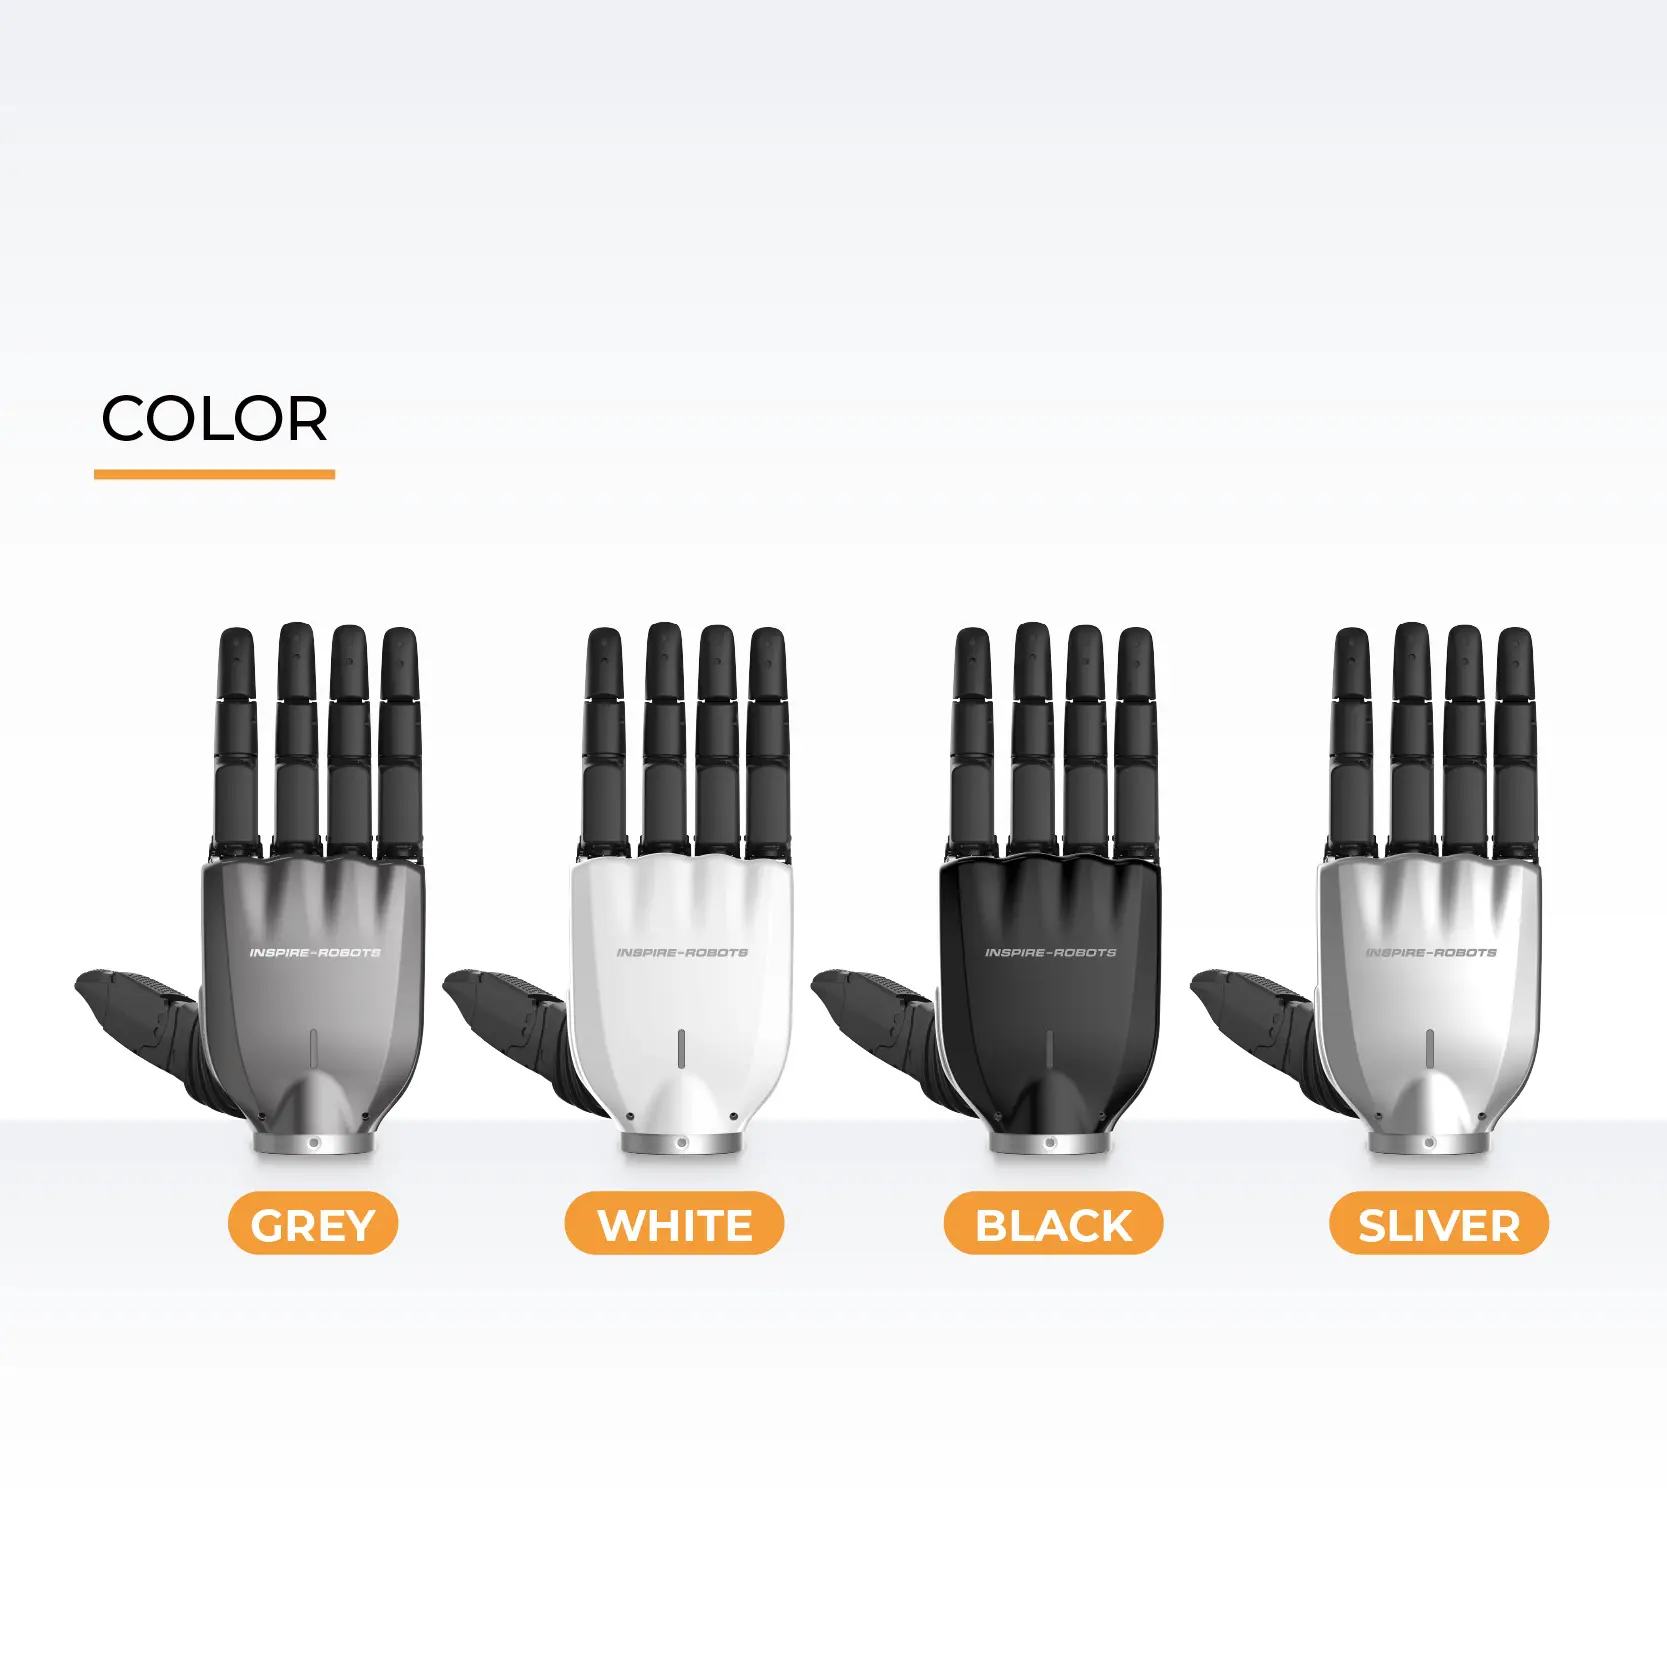
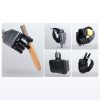
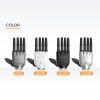
13 active DOF, 18 movable joints, anthropomorphic hand‑sized form factor, lightweight, high grasping force.
| Model | RH5DG2‑E4R‑T1 (Right hand model) | RH5DG2‑E4L‑T1 (Left hand mode) |
| Control interface | EtherCAT+CAN FD | EtherCAT+CAN FD |
| Degrees of freedom | 13 | 13 |
| Numbers of joints | 18 | 18 |
| Weight | 1020±15g(excluding wrist) | 1020±15g(excluding wrist) |
| Operating voltage | 18V~60V | 18V~60V |
| Quiescent current | 310±20mA (24V) | 310±20mA (24V) |
| Peak current | 7.5A @24V | 7.5A @24V |
| Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Strength | ≥20N | ≥20N |
| Fingertip Strength | ≥10N | ≥10N |
| Force resolution | 0.1N | 0.1N |
| Lateral rotation range of thumb | 65°‑175° | 65°‑175° |
| Index/Middle finger lateral swing | ±15° | ±15° |
| Maximum pressure on fingertip | 8kg | 8kg |
| Range of tactile sensor | 30N | 30N |
| Tactile sensor accuracy | 5%FS | 5%FS |
| Number of tactile sensors | 8 | 8 |
| Hand closing time | ≤0.8s | ≤0.8s |
| Model | RH5DG2‑E2R‑T1 (Right hand model) | RH5DG2‑E2L‑T1 (Left hand mode) |
| Control interface | EtherCAT+RS485 | EtherCAT+RS485 |
| Degrees of freedom | 13 | 13 |
| Numbers of joints | 18 | 18 |
| Weight | 1020±15g(excluding wrist) | 1020±15g(excluding wrist) |
| Operating voltage | 18V~60V | 18V~60V |
| Quiescent current | 310±20mA (24V) | 310±20mA (24V) |
| Peak current | 7.5A @24V | 7.5A @24V |
| Repeatability | ±0.2mm | ±0.2mm |
| Thumb Fingertip Strength | ≥20N | ≥20N |
| Fingertip Strength | ≥10N | ≥10N |
| Force resolution | 0.1N | 0.1N |
| Lateral rotation range of thumb | 65°‑175° | 65°‑175° |
| Index/Middle finger lateral swing | ±15° | ±15° |
| Maximum pressure on fingertip | 8kg | 8kg |
| Range of tactile sensor | 30N | 30N |
| Tactile sensor accuracy | 5%FS | 5%FS |
| Number of tactile sensors | 8 | 8 |
| Hand closing time | ≤0.8s | ≤0.8s |