Document 3: March 2026 – INSPIRE ROBOTS Stuns at 2026 Science Fiction Convention with World Premiere of New Compact Dexterous Hand
On March 27, the highly anticipated 2026 Science Fiction Convention officially opened at Beijing’s Shougang Park. At this premier event gathering cutting-edge technologies, INSPIRE ROBOTS, as a global leader in dexterous manipulation, made a major appearance with its new series of dexterous hands and embodied AI demonstration solutions, showcasing its innovative achievements in dexterous manipulation to professional audiences on-site.
At this Science Fiction Convention, INSPIRE ROBOTS unveiled its latest-generation compact dexterous hand—the RH56H1 Series (H1 Series) —once again disrupting industry perceptions with the advantage of “extremely compact, absolutely powerful.” The H1 Series breaks the upper limit of gripping force for compact dexterous hands, achieving a perfect balance between small form factor and powerful grip—a testament to INSPIRE ROBOTS’ continuous iteration capability in the dexterous hand sector.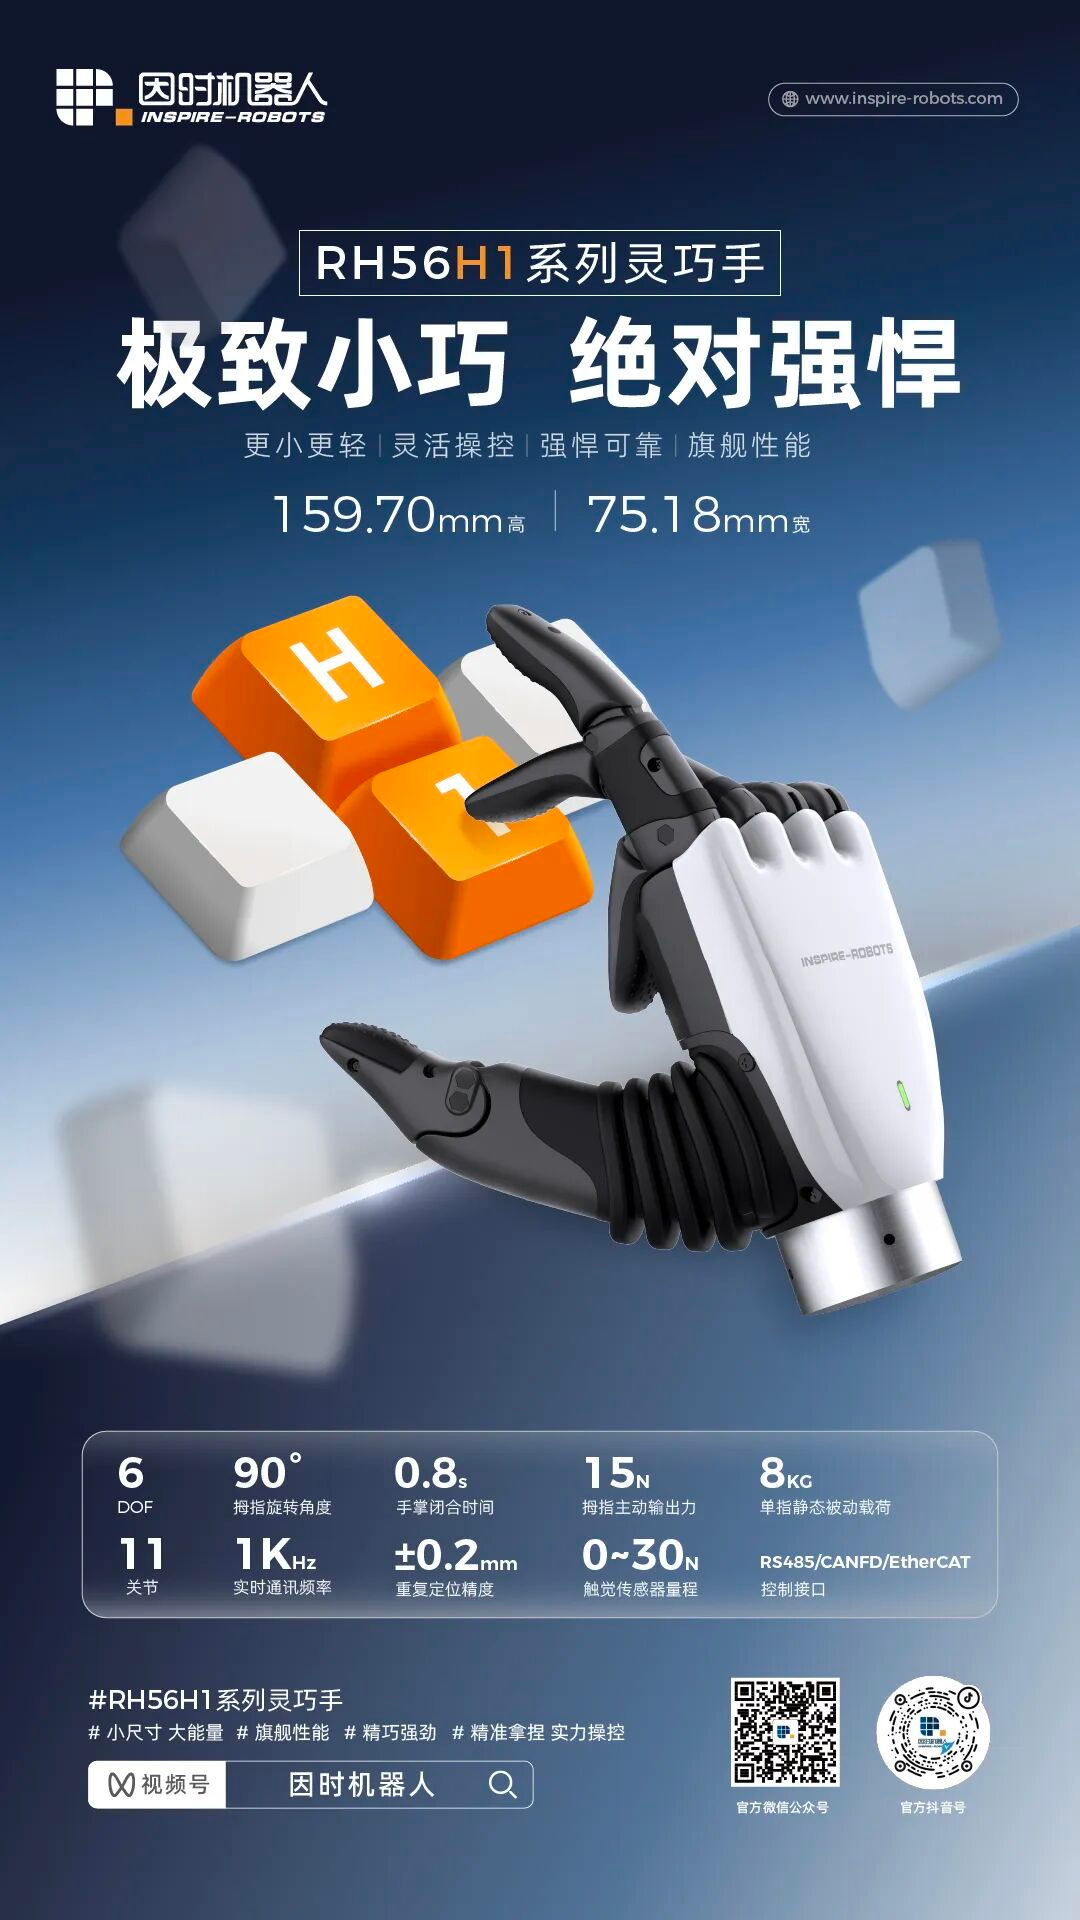
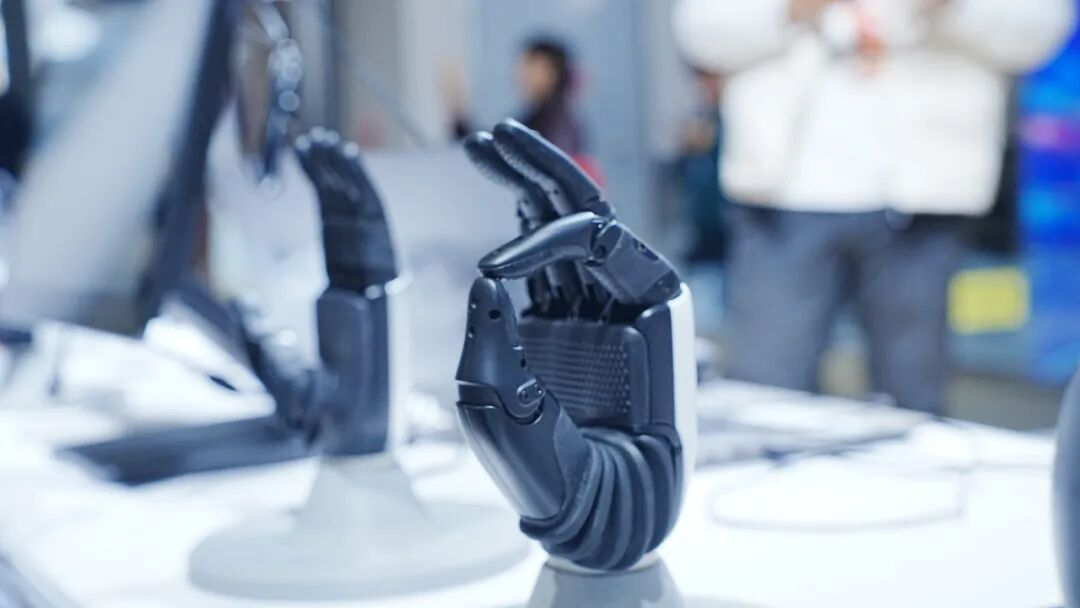
At the exhibition site, the H1 Series’ outstanding performance was demonstrated through various motion and grasping demonstrations.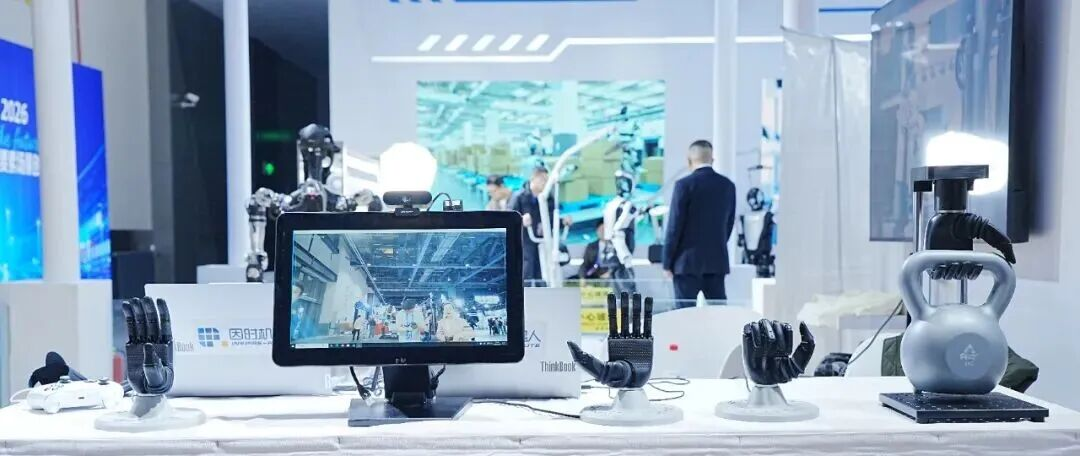 In fixed-action demonstrations, the H1 Series smoothly performed multiple anthropomorphic gestures including two-finger pinch, fist clenching, extension, and bending. This dexterous hand features 6 active degrees of freedom and 5 passive degrees of freedom, totaling 11 joints, with each joint’s independent motion and multi-finger coordination clearly presenting its motion execution capabilities.
In the heavy-load grasping demonstration, the compact H1 Series dexterous hand steadily grasped a 5kg kettlebell and completed a series of actions including lifting,平移, and placement. The visual impact of a small, child-sized robotic hand lifting a 5kg kettlebell amazed the audience! This vividly verified the H1 Series’ powerful load capacity within an extremely compact form factor—truly demonstrating what “small size, big power” means.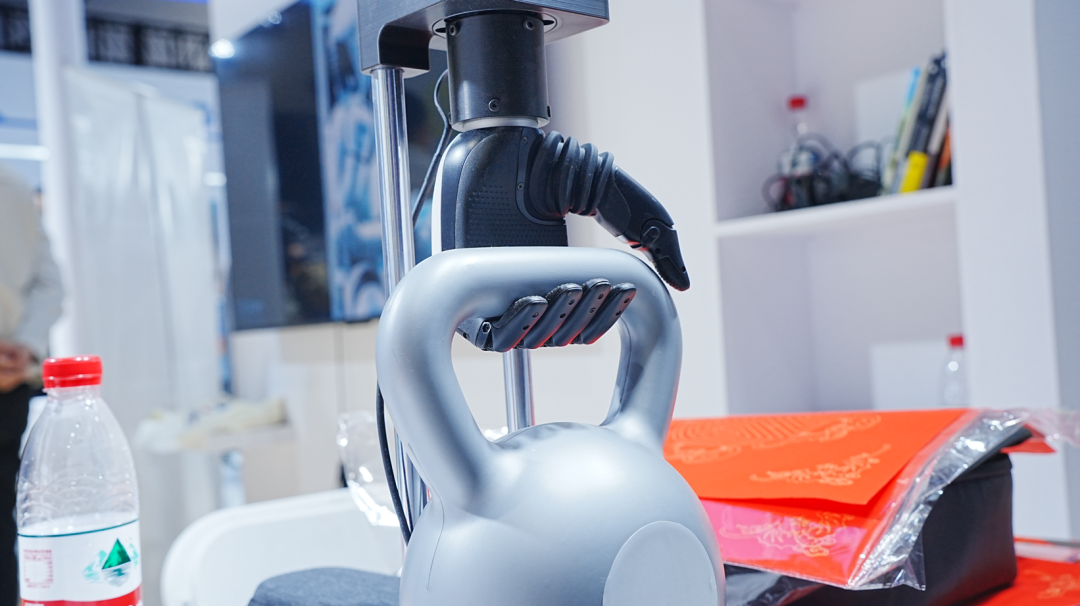
The H1 Series’ real-time responsiveness is equally outstanding. In the visual tracking demonstration, a camera captured human hand gestures in real time—whether five-finger spreading, fist clenching, or independent flexion of specific fingers—and the H1 Series quickly replicated the corresponding movements. In the teleoperation demonstration, visitors wearing data gloves performed various hand movements, and the H1 Series dexterous hand precisely synchronized with them, comprehensively showcasing its rapid response advantages in human-robot interaction and teleoperation control scenarios.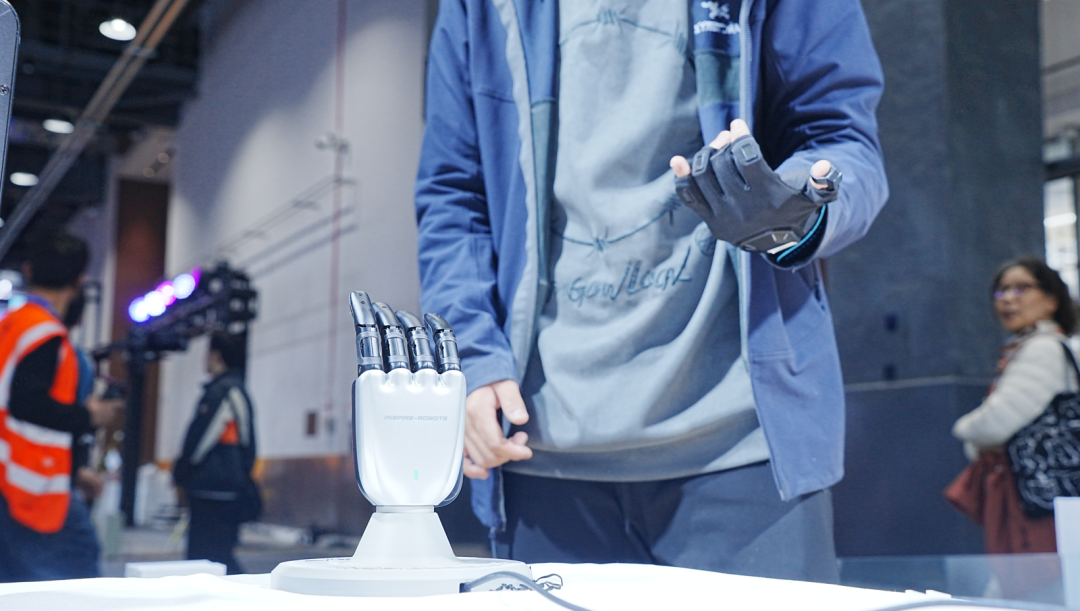
Beyond the H1 Series new product launch, INSPIRE ROBOTS also exhibited its full range of dexterous hand products from the third to seventh generations. This complete product matrix meets both the high-reliability and mass-production needs of embodied AI robotics companies and provides diversified hardware support for cutting-edge exploration in dexterous manipulation, demonstrating INSPIRE ROBOTS’ technological depth in the field.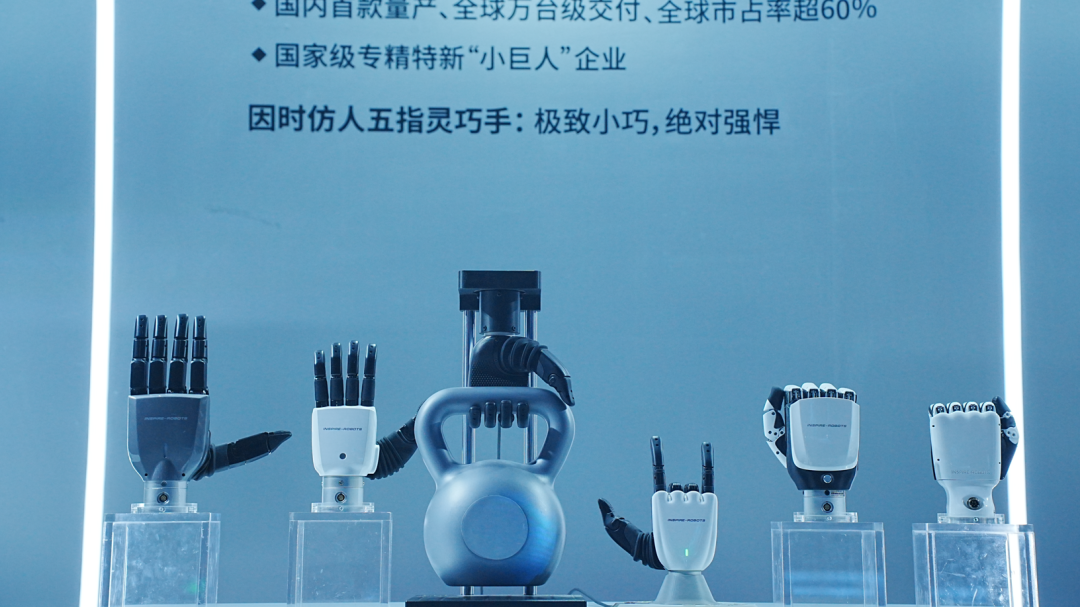
Centered on the core proposition of “dexterous manipulation,” INSPIRE ROBOTS set up two dynamic demonstrations, interpreting from different dimensions the boundary of robotic interaction with the physical world. At the robot calligraphy demonstration area, a robot equipped with the E2 Series dexterous hand steadily held a brush and wrote a clear “福” (fortune) character on rice paper. Through the coordination of dexterous hands and flexible dual arms, it broke the rigid perception of machinery and showcased the fusion of technology and traditional calligraphy. This test demonstrated INSPIRE ROBOTS’ dexterous hand’s grip force control capability and showcased industry-leading fine manipulation capabilities. The demonstration intuitively presented the advantages of “stable gripping, precise control, and strong coordination”—not just demonstrating writing ability, but also serving as strong proof of the dexterous hand’s reliability in high-end application scenarios such as precision assembly, medical surgery, and flexible grasping.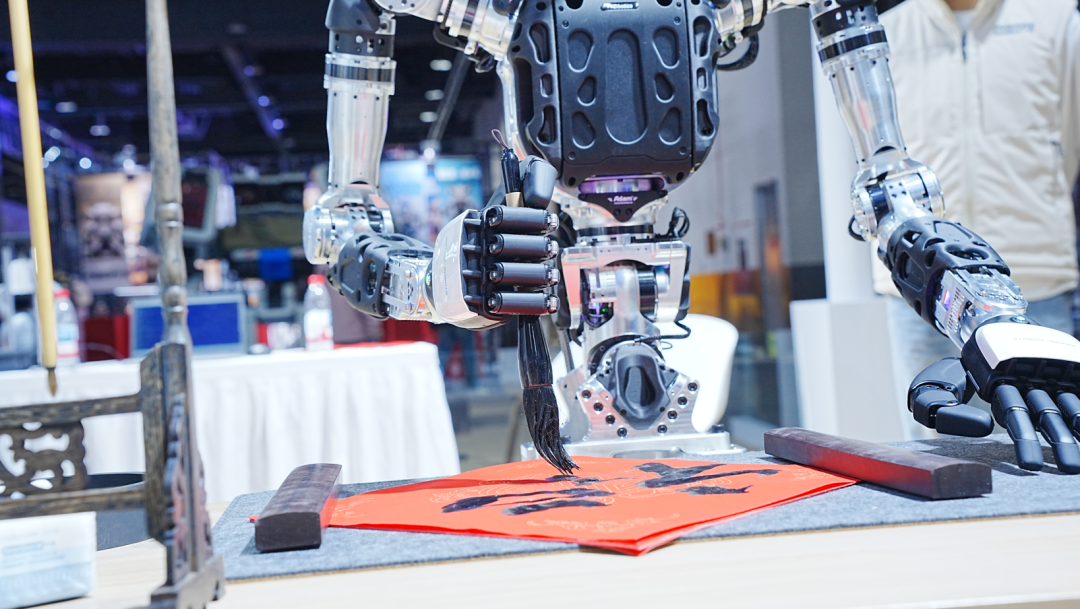
Robotic teleoperation data collection is an important method for gathering physical-world operation execution data. This process can transform human operational experience into data resources usable for model training, providing foundational support for robot imitation learning, reinforcement learning, and VLA model training. INSPIRE ROBOTS controlled the “arm + hand” system through teleoperation for grasping and sorting data collection, with the collected data fed back into reinforcement learning models to further enhance the dexterous hand’s generalized grasping capability.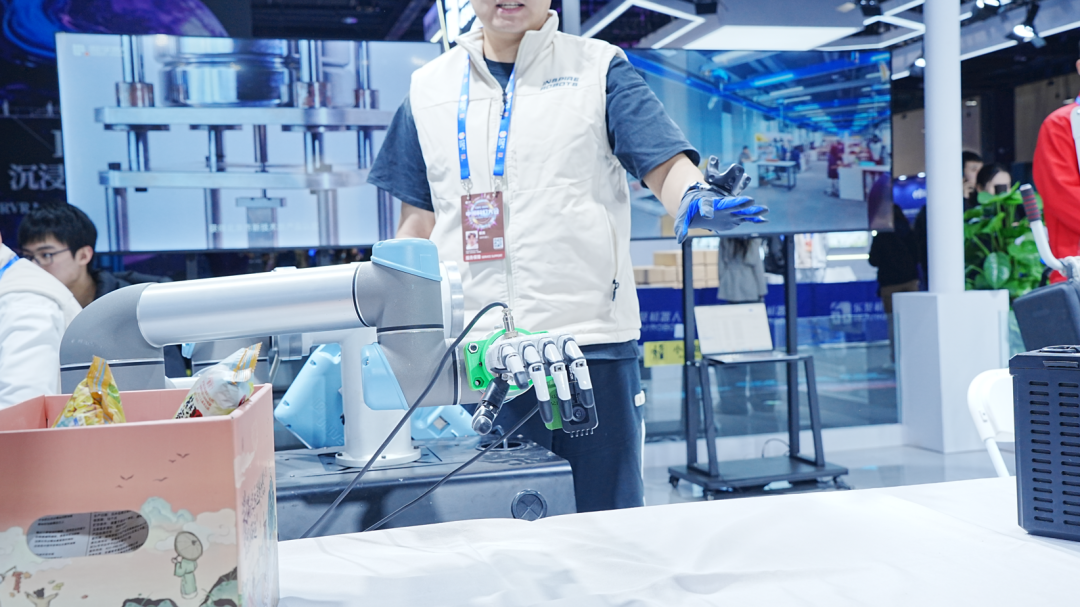
From the premiere of the H1 dexterous hand to the full-matrix exhibition, INSPIRE ROBOTS demonstrated its technological depth and product layout in dexterous manipulation at this Science Fiction Convention. Beyond technological depth, mass-production capability is equally critical in determining whether a core component enterprise can truly support industrial deployment.
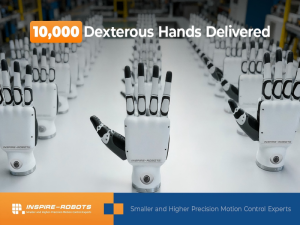
In 2025, INSPIRE ROBOTS’ annual dexterous hand deliveries exceeded 10,000 units, with Micro Linear Servo Actuators reaching an annual production capacity of 500,000 units. Behind this data lies INSPIRE ROBOTS’ powerful large-scale delivery capability, providing supply chain security for key execution components essential to the mass production of embodied AI robotics companies.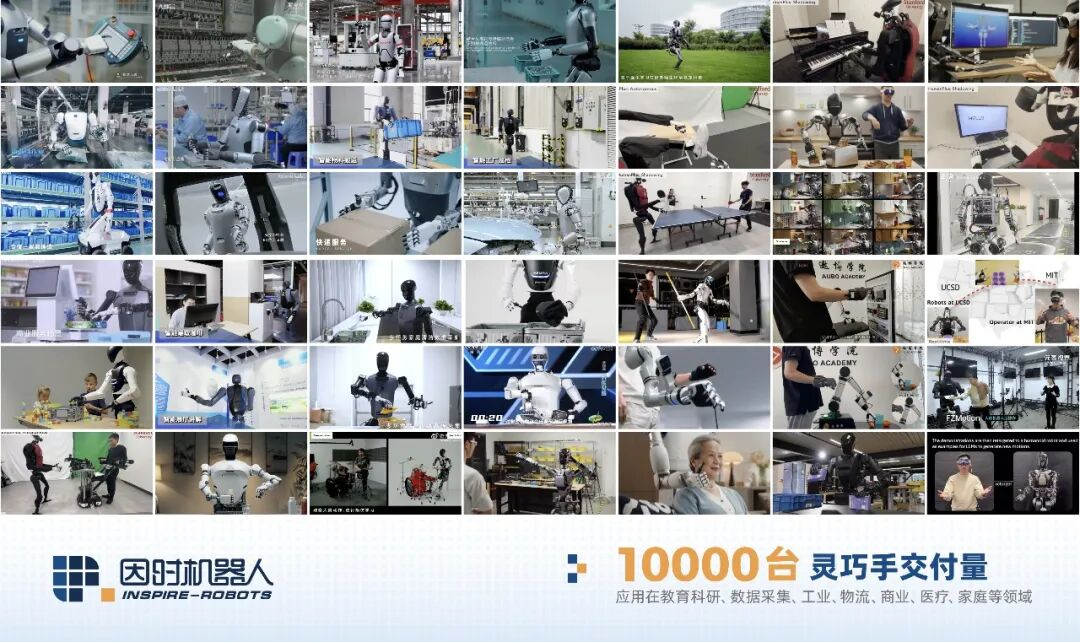
As humanoid robots transition from concept to industrial implementation, dexterous hands—as key end-effectors—are becoming a crucial factor determining the success of technological commercialization. INSPIRE ROBOTS, with its continuously iterating product matrix and vertically integrated industrial chain capabilities, is providing critical support for the large-scale implementation of embodied AI.