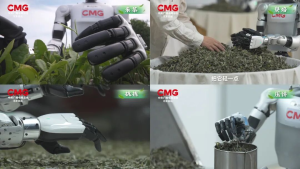
Following tea-picking in Fuding and dragon boat racing in Bazhong, the second World Humanoid Robot Games “Energy Transfer” third stop arrived in Xinjiang.
From tea mountains to rivers, and now to high-altitude grassland lakes, humanoid robots continue to step out of laboratories and face challenges in increasingly open and complex real-world environments. Playing the dombra, horse-mounted archery, skipping stones on the lake, outdoor tent pitching, and Xinjiang specialty food preparation—each challenge tests different dimensions of dexterous hand technical capabilities, becoming a real-scenario proving ground for INSPIRE ROBOTS’ full series of dexterous hands.
As the most representative challenge of this stop, the world’s first humanoid robot “mounted archery” made a stunning debut.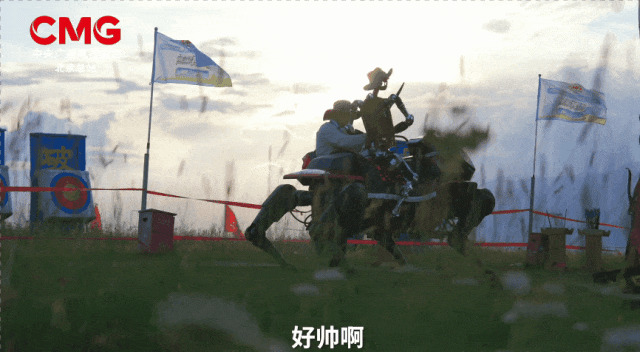
In an unstable dynamic environment, the dexterous hand not only had to grip and hold the bow but also withstand continuous tension during the bowstring-drawing process, and achieve rapid, precise release at the moment of arrow launch. This process placed extremely high demands on the dexterous hand’s gripping force, multi-finger coordinated control, response speed, and structural reliability.
During the bow-drawing process, the sustained tension of the bowstring posed a rigorous test of the dexterous hand’s gripping force and structural reliability. At the moment of release, the dexterous hand was required to demonstrate high-speed response and precise control capabilities.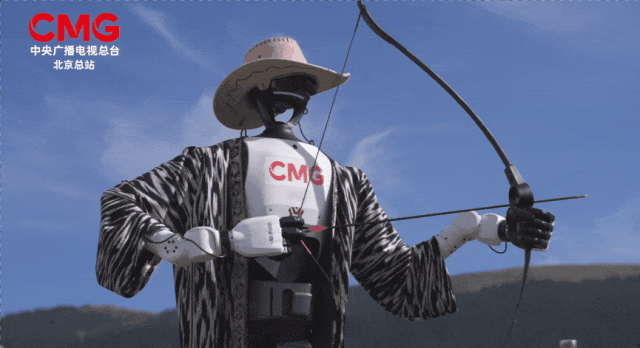
In this challenge, the RH5DG2, with 13 active degrees of freedom, 18 motion joints, and 20N fingertip gripping force, stably completed the continuous fine-motion sequence of bow gripping, bow drawing, and arrow release. 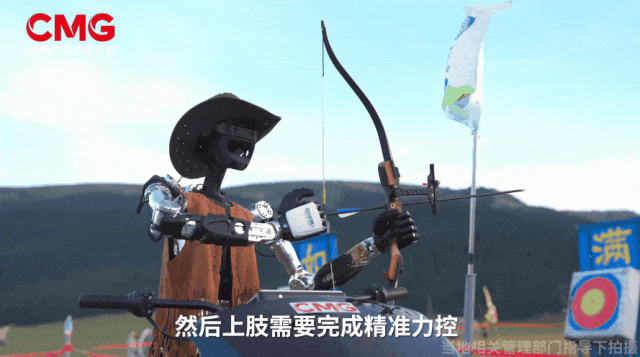
The RH56E2, when performing the bowstring-pulling task, relied on its industrial-grade high reliability and powerful fingertip gripping force to maintain stable performance under continuous bowstring tension through multiple cycles of testing, providing reliable support for the archery performance.
Skipping stones may seem simple, but it places extremely high demands on the dexterous hand’s high-speed dynamic control capabilities. The robot must seize the optimal release moment during the stone’s high-speed motion while maintaining proper release speed, angle, and spin to achieve stable water entry and continuous bouncing.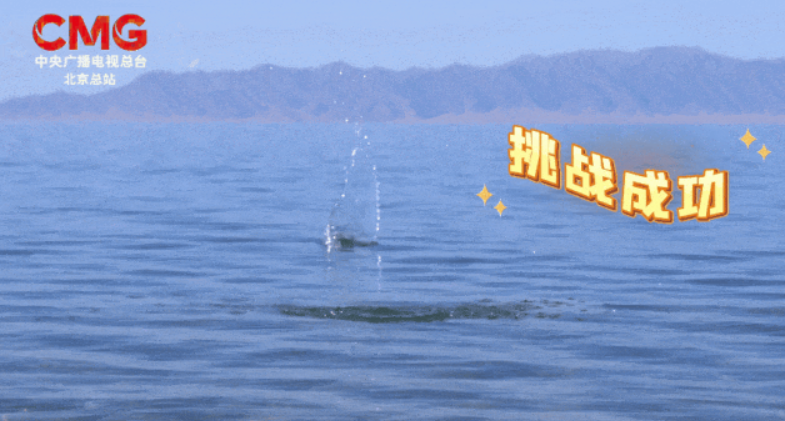 In the stone-skipping real-scenario challenge, the RH56BFX, with its high-speed dynamic response and precise force control capabilities, completed a series of continuous actions including stone gripping, instant release, and long-distance throwing, fully demonstrating the BFX Series’ operational capabilities in high-speed dynamic manipulation scenarios.
By the shores of Sayram Lake, the robot first took on the challenge of playing the dombra—a traditional Xinjiang instrument. The dombra is a compact instrument with only two strings, requiring playing techniques of plucking, picking, and sweeping, imposing strict size limitations on the robotic dexterous hand.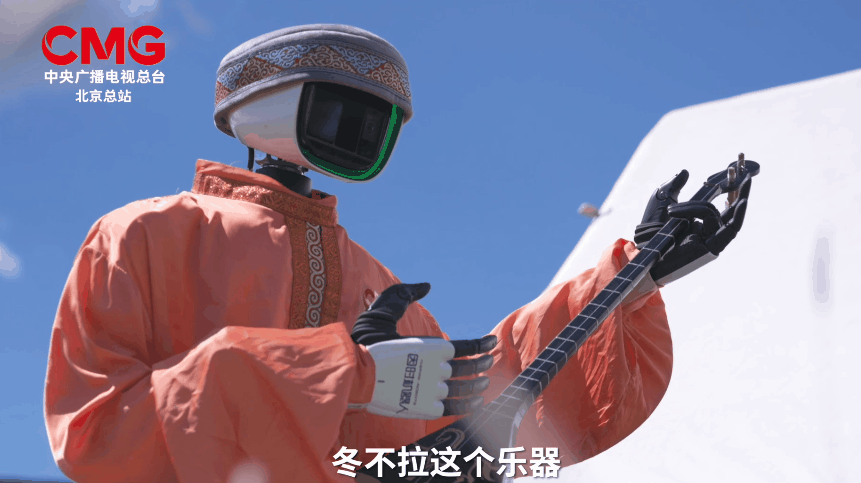
The RH56H1 Series, as a compact dexterous hand, perfectly achieved smooth dual-hand coordinated performance. After completing the musical performance, the robot took on the tent-pitching challenge. Inflating the tent required the dexterous hand to continuously press the pump with sustained force, maintaining stable grip and continuous power output over an extended period—a significant test of the dexterous hand’s gripping force and stability.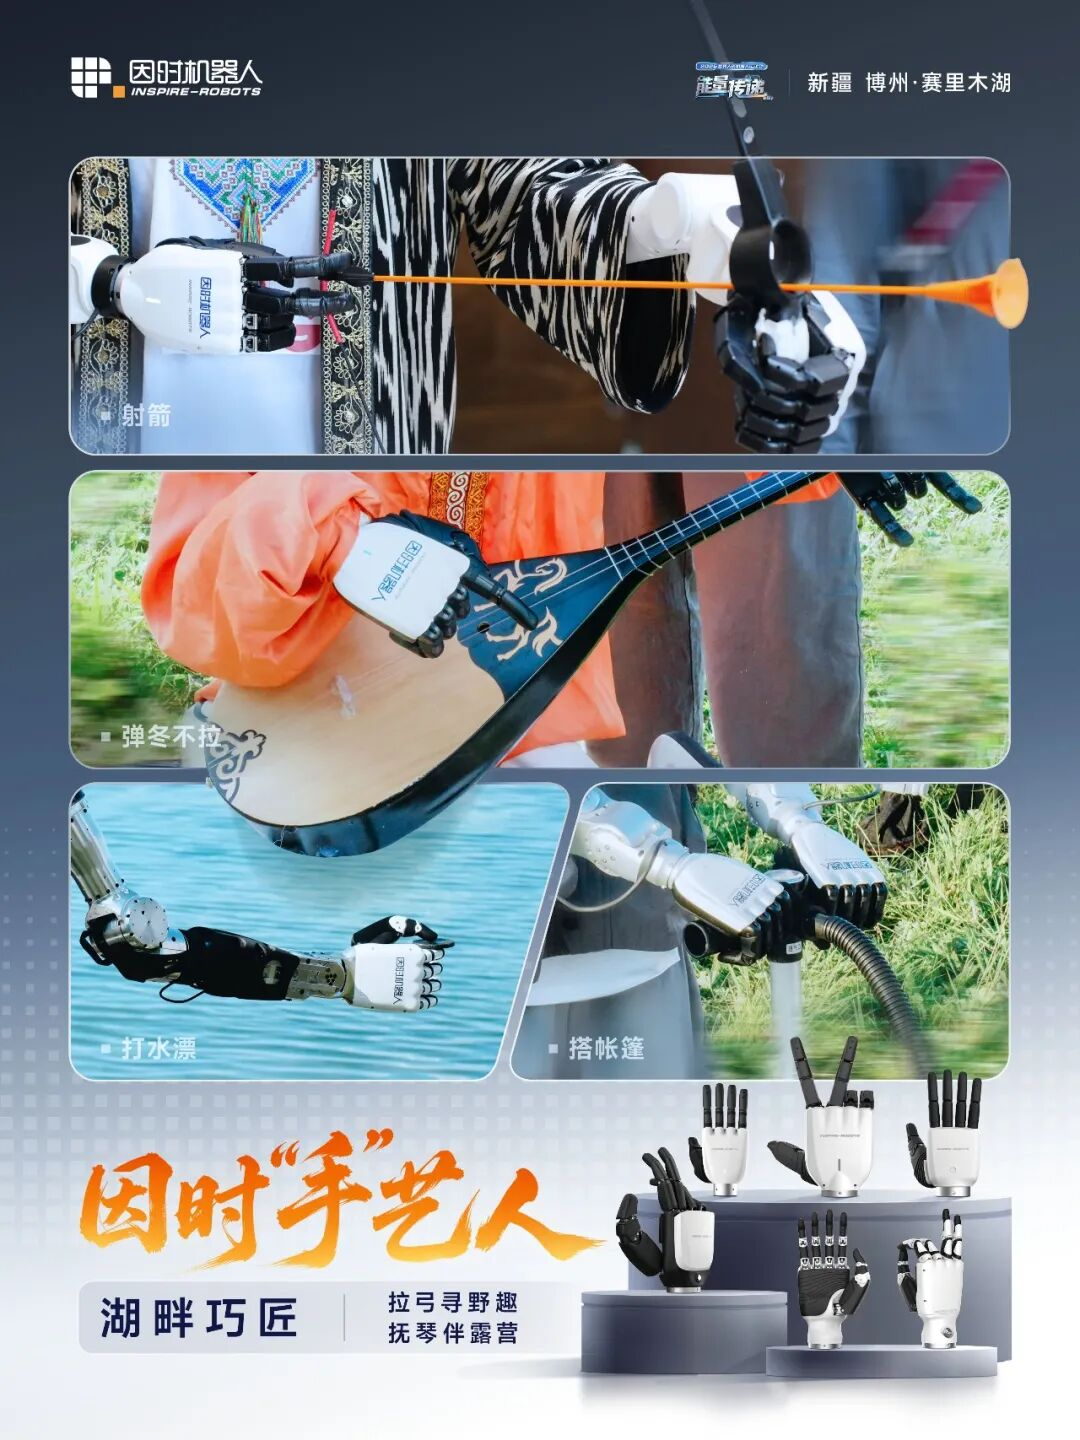
From musical instrument performance to camping setup, the H1 dexterous hand spanned completely different application scenarios, demonstrating both precision operation capability and reliable operational ability in open environments.
Xinjiang specialty food preparation represented a brand-new challenge for robots in real-life scenarios.
The first challenge was skewering lamb. The robot first had to grasp the lamb meat and thread it onto skewers. Lamb meat has a smooth surface with low friction, while the skewers are thin and long, imposing extremely high requirements on clamping stability, clamping force, and precise alignment capability. Facing this challenge, the RH56F02 Series, with its stable gripping capability, precise positioning, and adaptive force control, achieved the perfect balance of “stable, precise, and firm,” successfully completing stable grasping and precise skewering.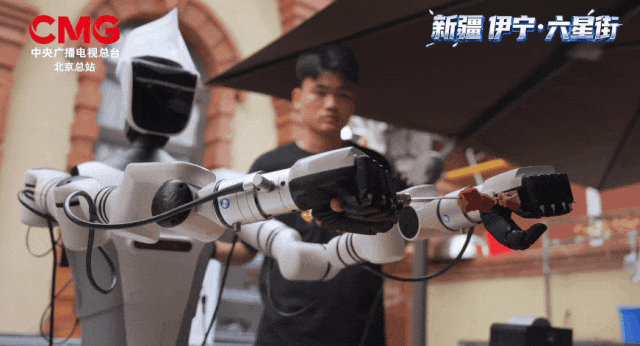
Next came the grilling phase. High-temperature charcoal exposed the dexterous hand to prolonged high-heat conditions, requiring not only resistance to temperature effects on control and operation but also sustained stable gripping and precision operation under high heat. Long-duration, high-frequency grilling actions posed a rigorous test of the dexterous hand’s high-temperature resistance, operational stability, and reliability.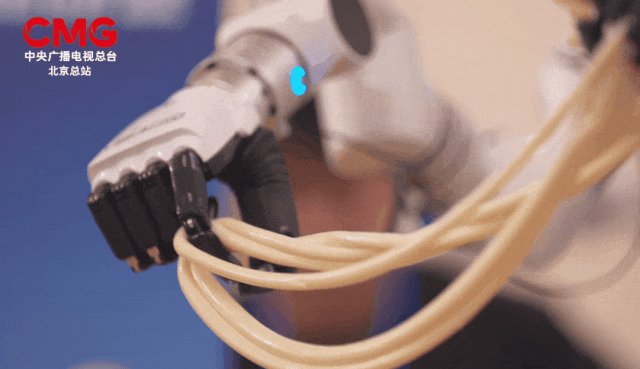
For food preparation scenarios, the RH56F02 uses food-grade safety materials that meet food-contact requirements and has been specifically optimized for waterproofing, oil resistance, and ease of cleaning, making it adaptable to complex operational environments in food preparation, providing cutting-edge validation for robots entering real application scenarios such as catering and life services.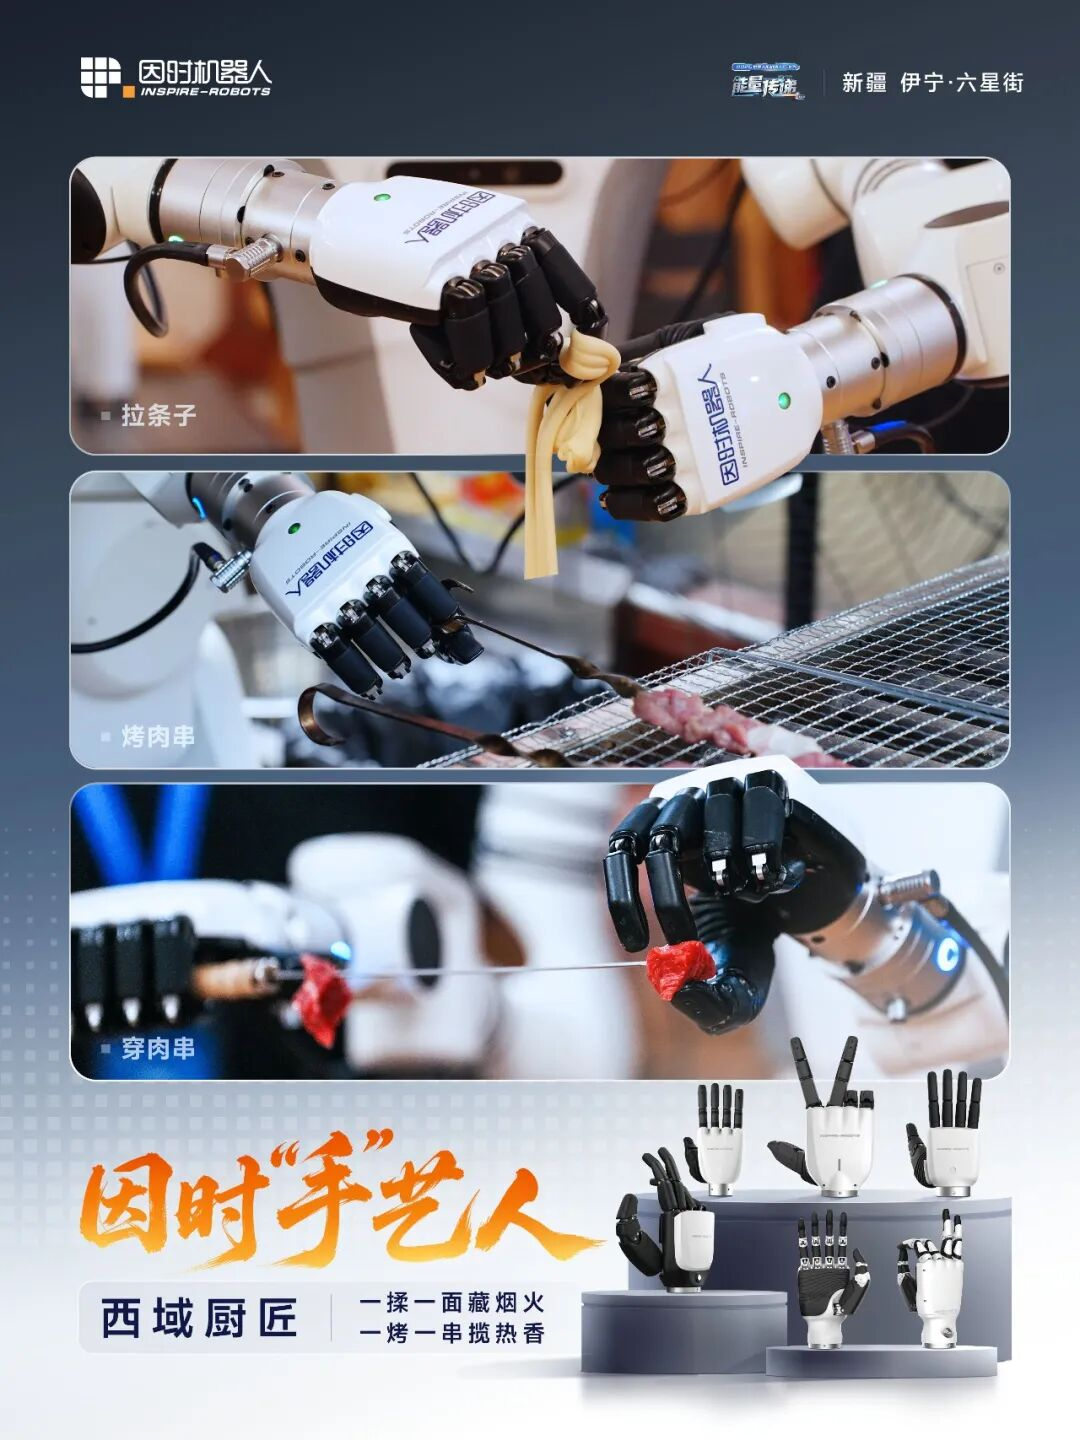
Xinjiang pulled noodle (laghman) preparation raised the difficulty again. As stretching continued, the noodles became thinner and softer, highly testing the dexterous hand’s fine manipulation capability. Throughout the process, the dexterous hand not only had to precisely control clamping force but also adjust motion rhythm in real time based on dough texture changes—ensuring no breaking or sticking while completing continuous stretching—requiring high-precision force control with dynamic adjustment capability.
From tea-picking and processing in Fuding, Fujian, to dragon boat racing in Bazhong, Sichuan, to the world premiere of humanoid robot mounted archery in Xinjiang, INSPIRE ROBOTS continues to drive dexterous manipulation technology into the real world, verifying product performance through continuously escalating real-scenario challenges.
Different products correspond to different capabilities; different capabilities support different scenarios—together building INSPIRE ROBOTS’ dexterous hand product matrix covering precision operations, high-load operations, flexible services, and high-speed dynamic interactions.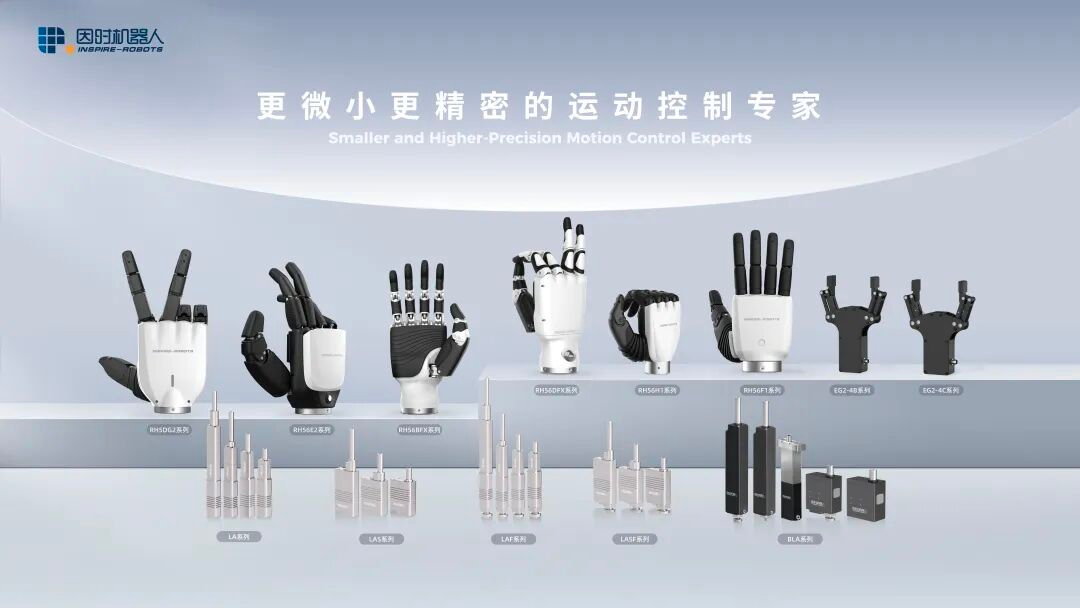
Every precise grasp, every stable output, and every successful challenge originates from the real “energy” of dexterous manipulation. This energy gathered from the real world will converge at the August World Humanoid Robot Games. Where will this energy bloom next? Let’s wait and see!